Claw mechanism
CAD design
I led the development team in modeling the drone claw and arm mechanism in Fusion 360. Paired gears coordinate the curved jaws, while the arm model lays out the parallel supports and pivot connections. The videos below show the main stages of development throughout the season. They do not capture the final adjustments to arm weight and claw size, which another team member handled.
Bringing models into reality
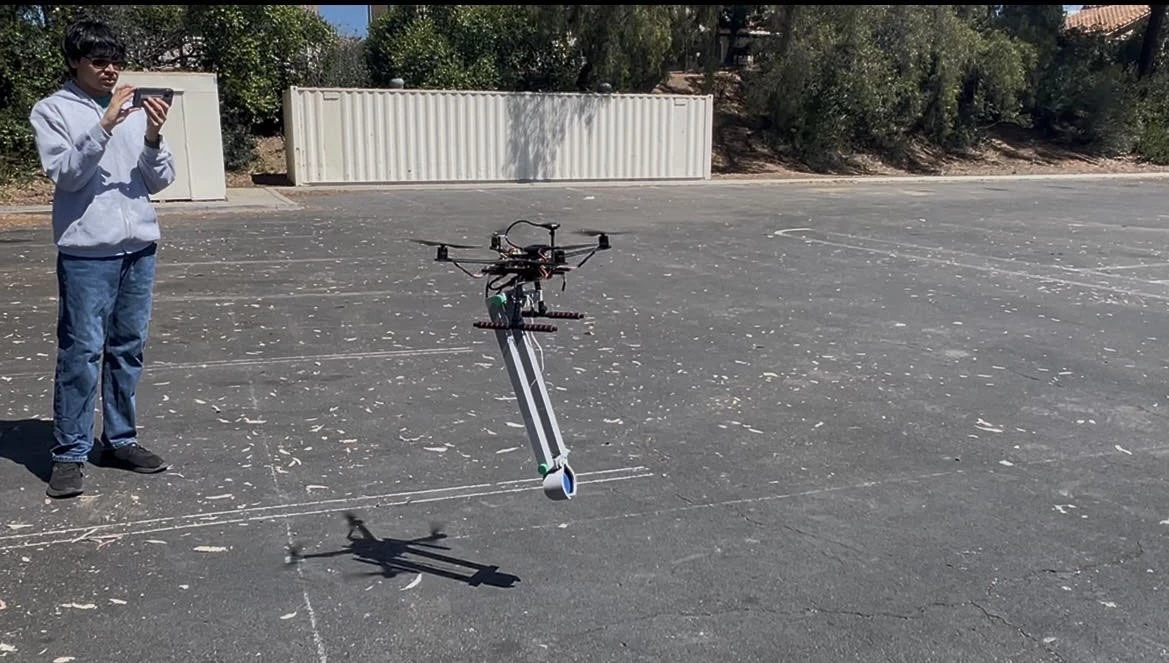
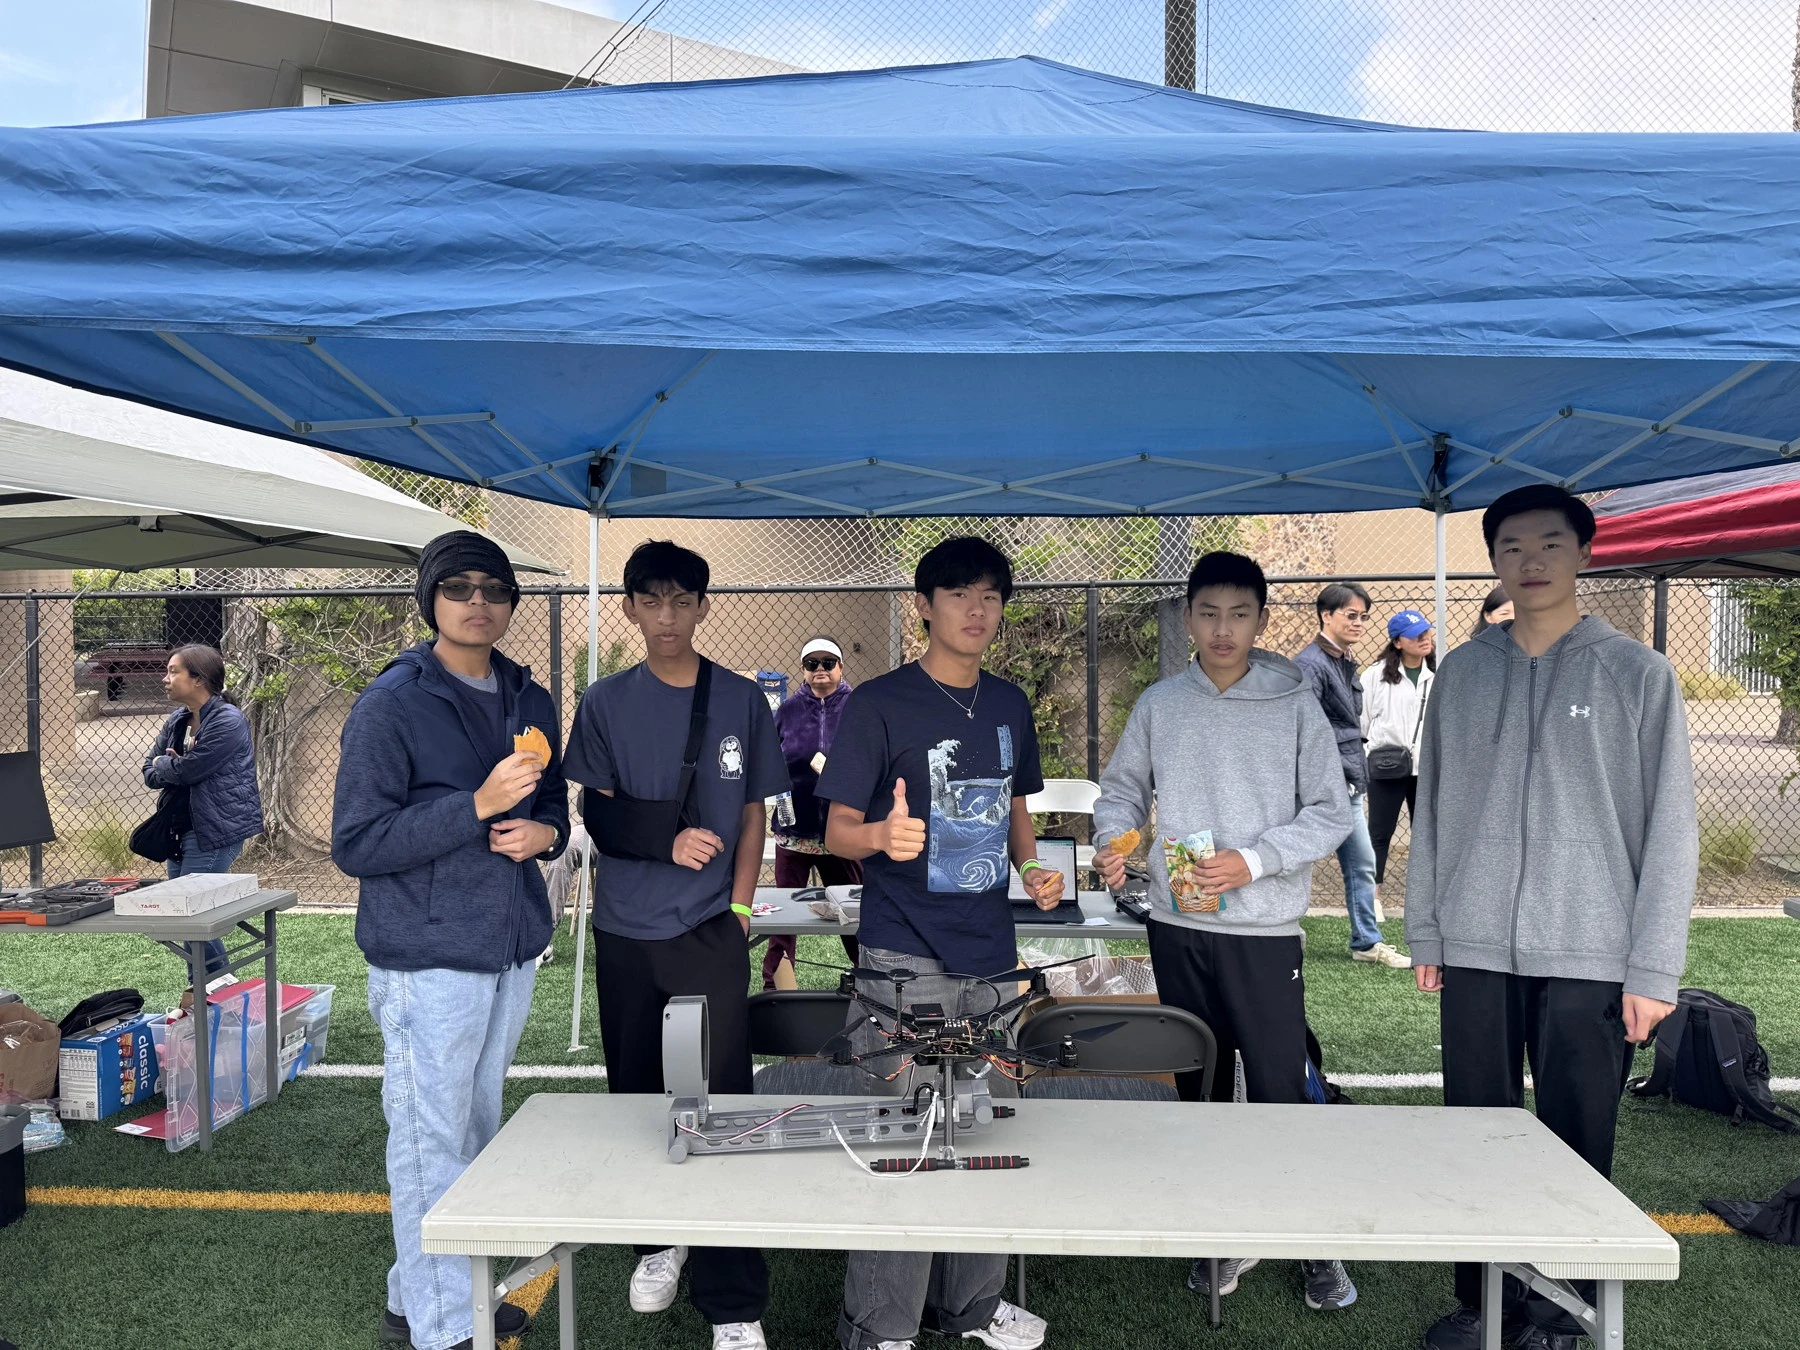
The printed versions bring the mechanism off the screen. Across these iterations, we revised the jaw shapes, arm connections, and gripping surfaces, leading to a final mechanism mounted beneath the drone.
- 01
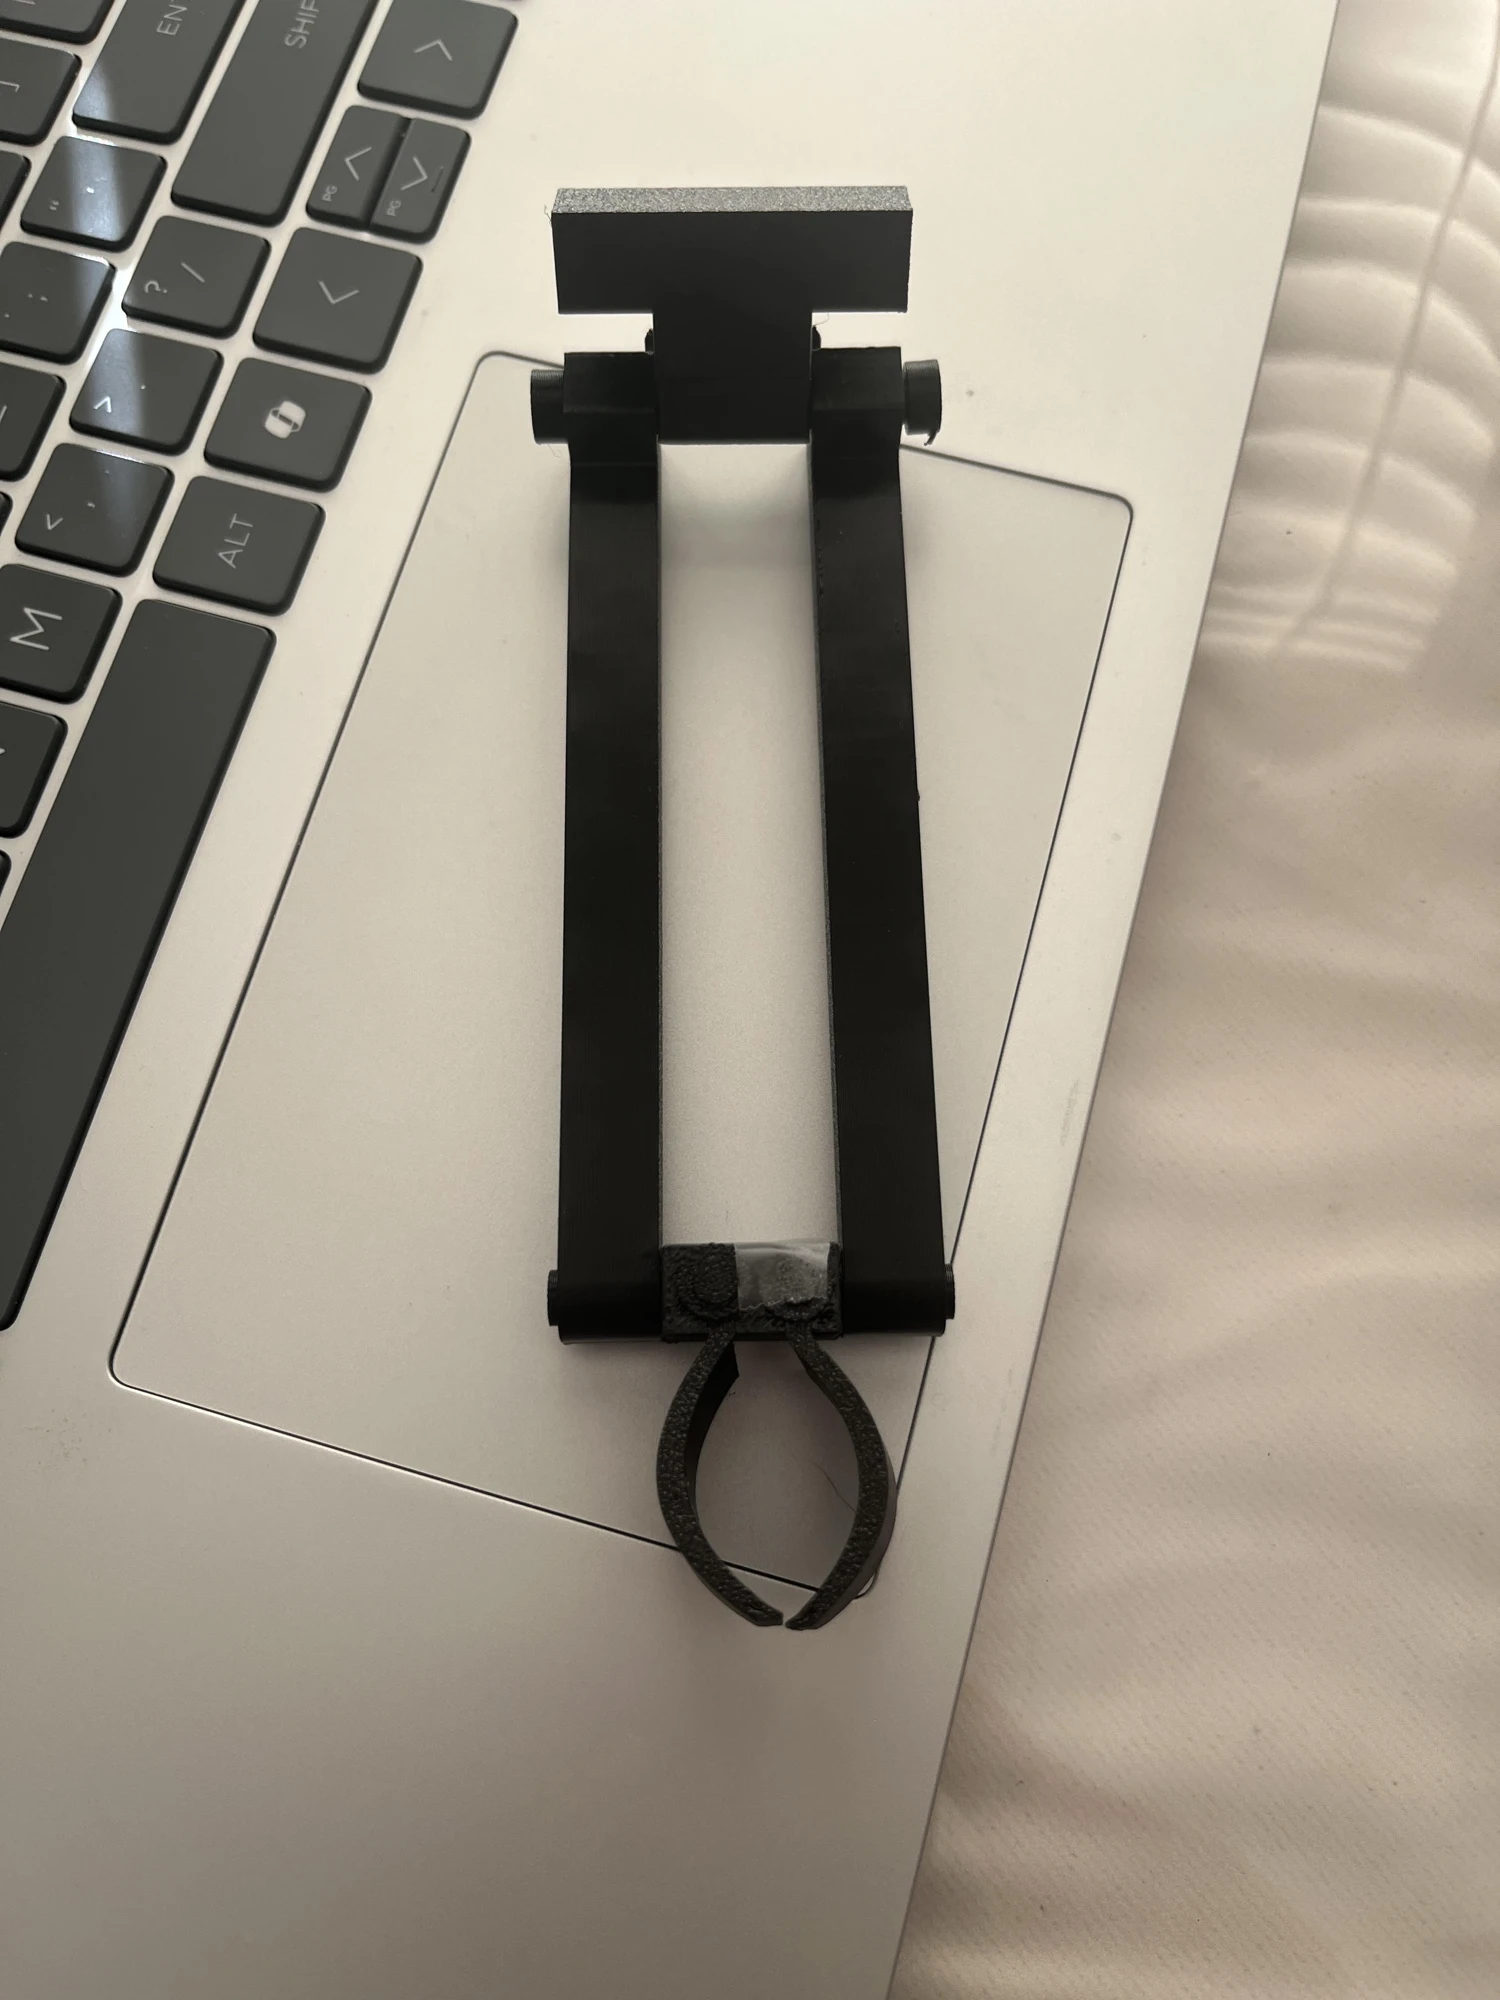
This first model was a miniature prototype, designed to make the concept tangible—to see it in three dimensions and get a feel for the mechanism beyond the CAD screen.
- 02
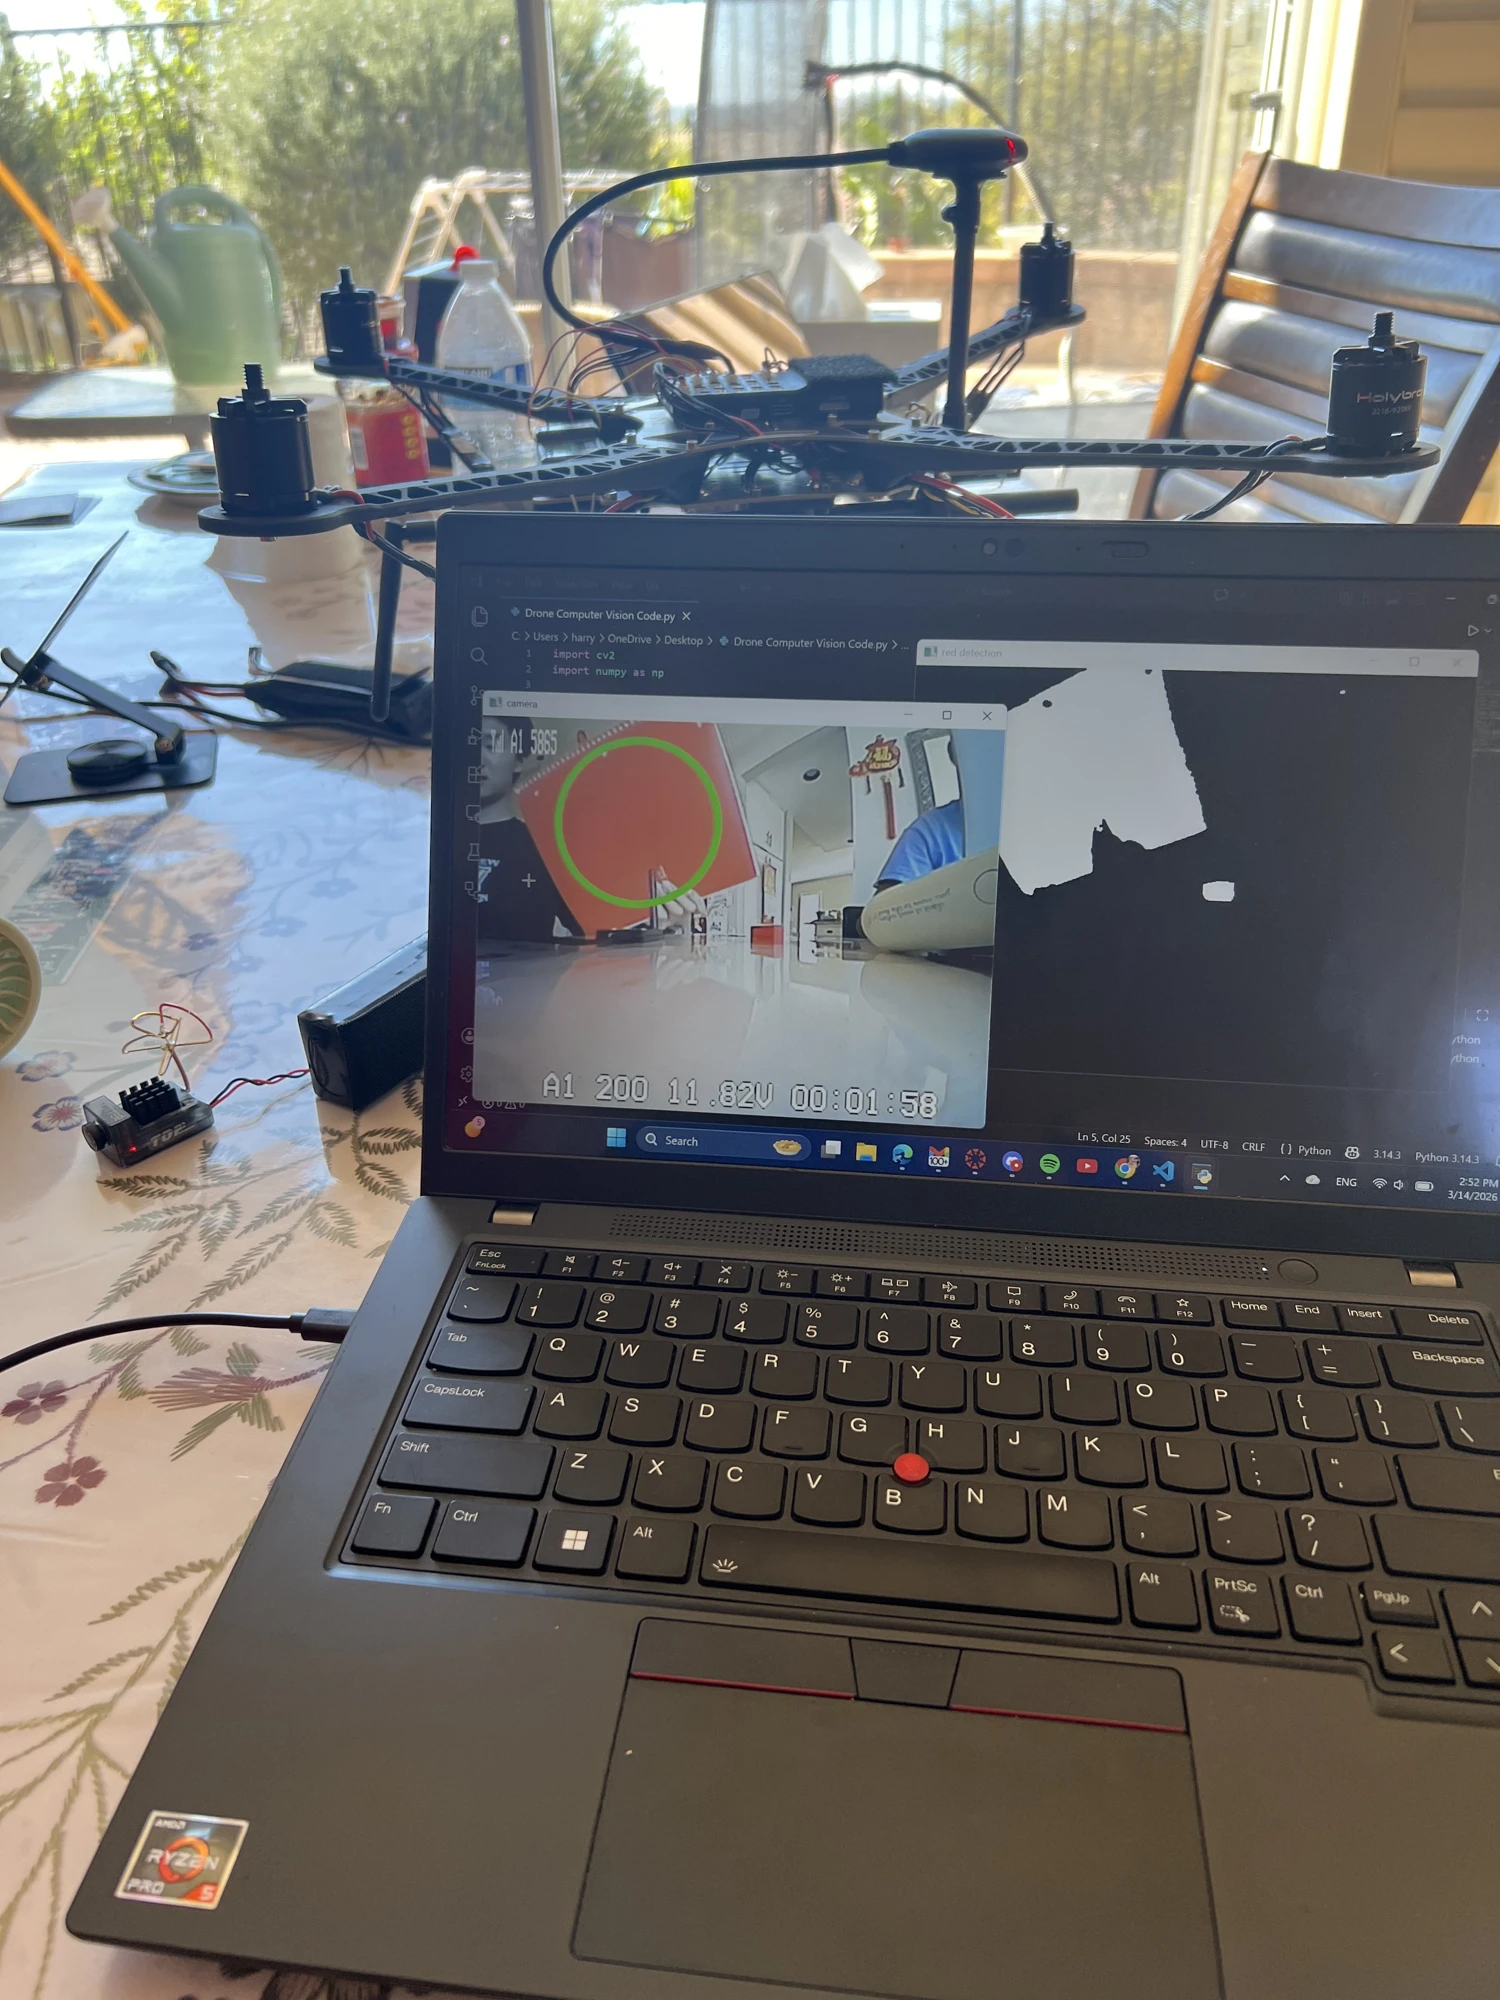
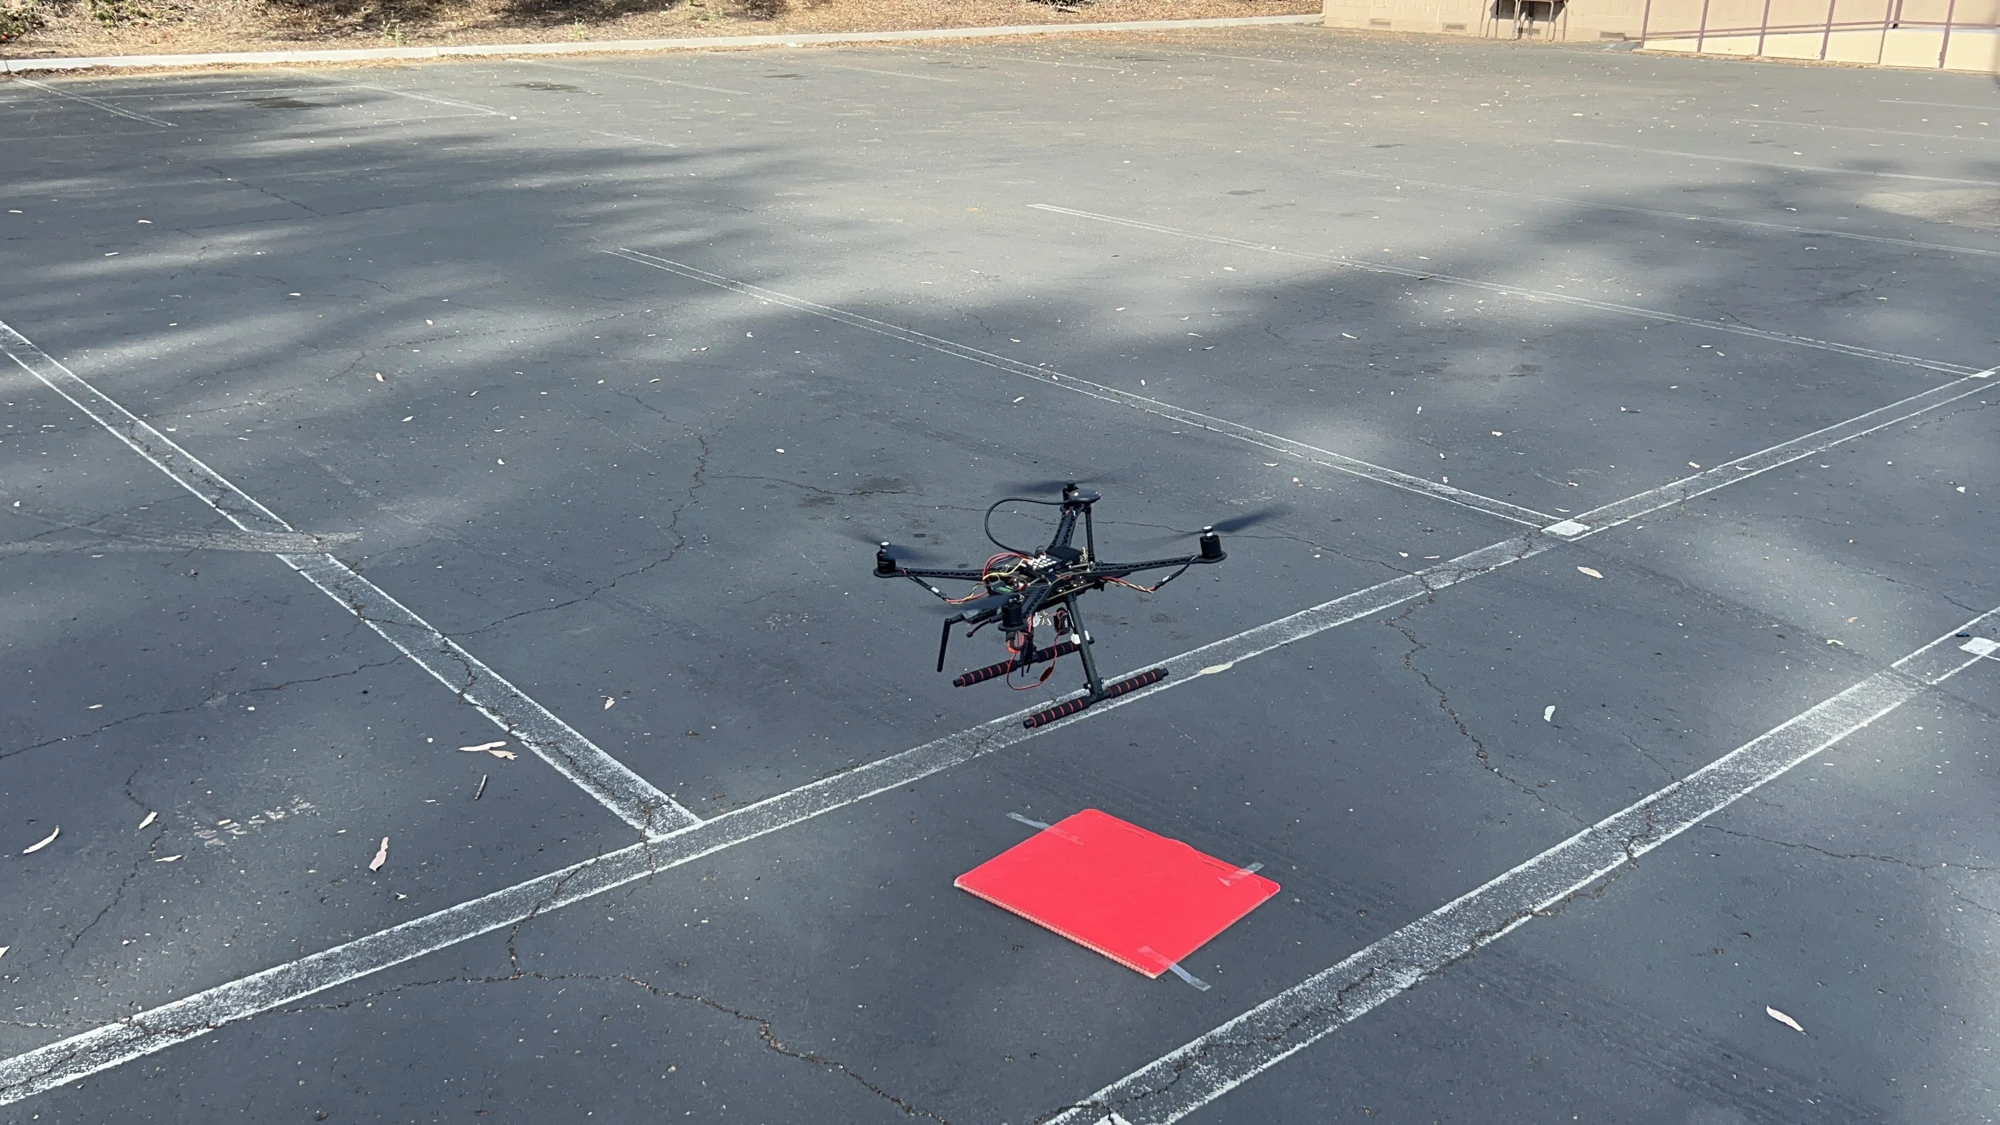
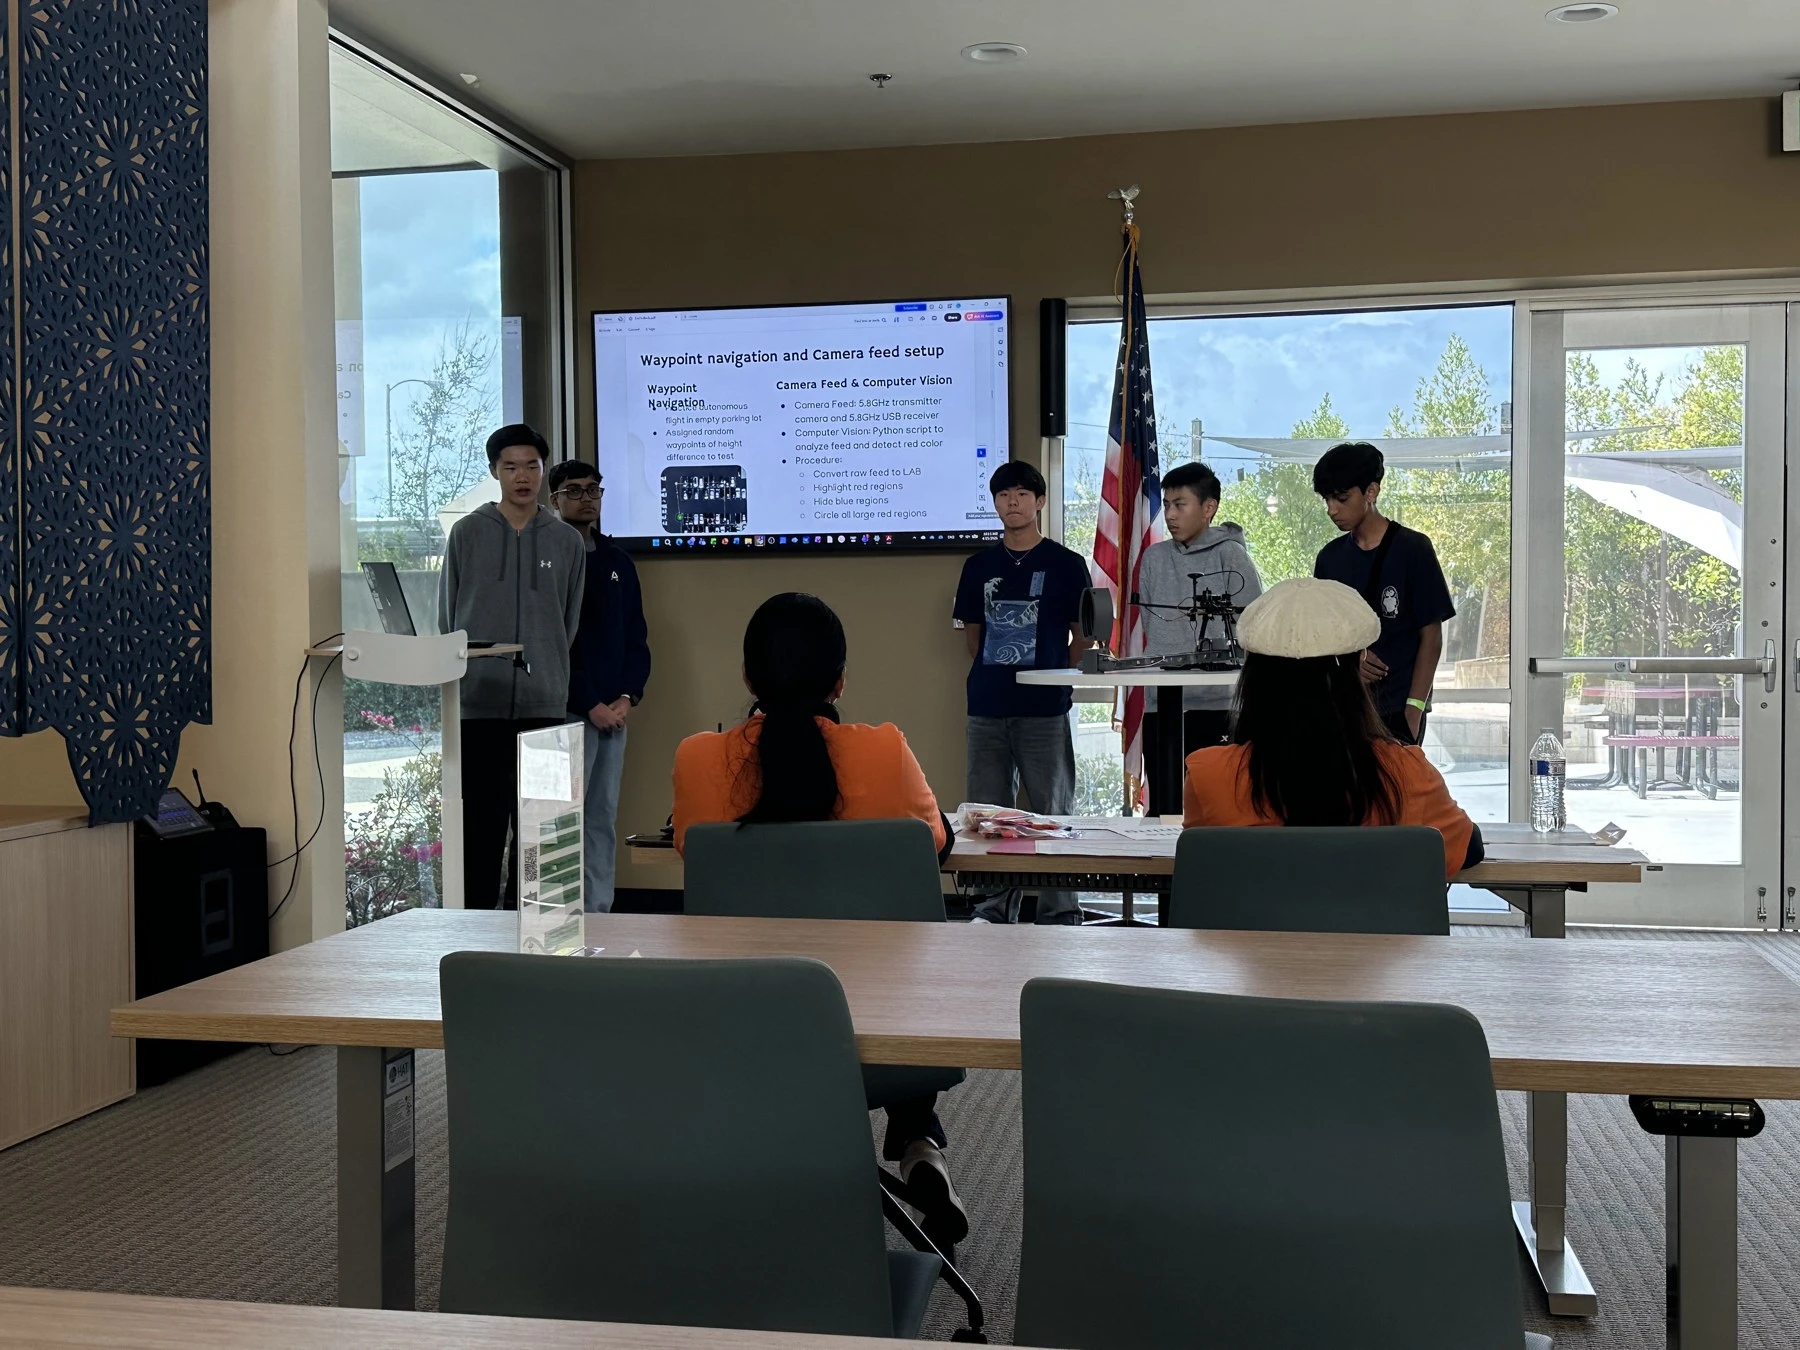
The computer vision program uses Python and OpenCV to detect red. On the laptop, the left frame circles the detected red region, while the right frame shows it as a white mask against a black background.
- 03
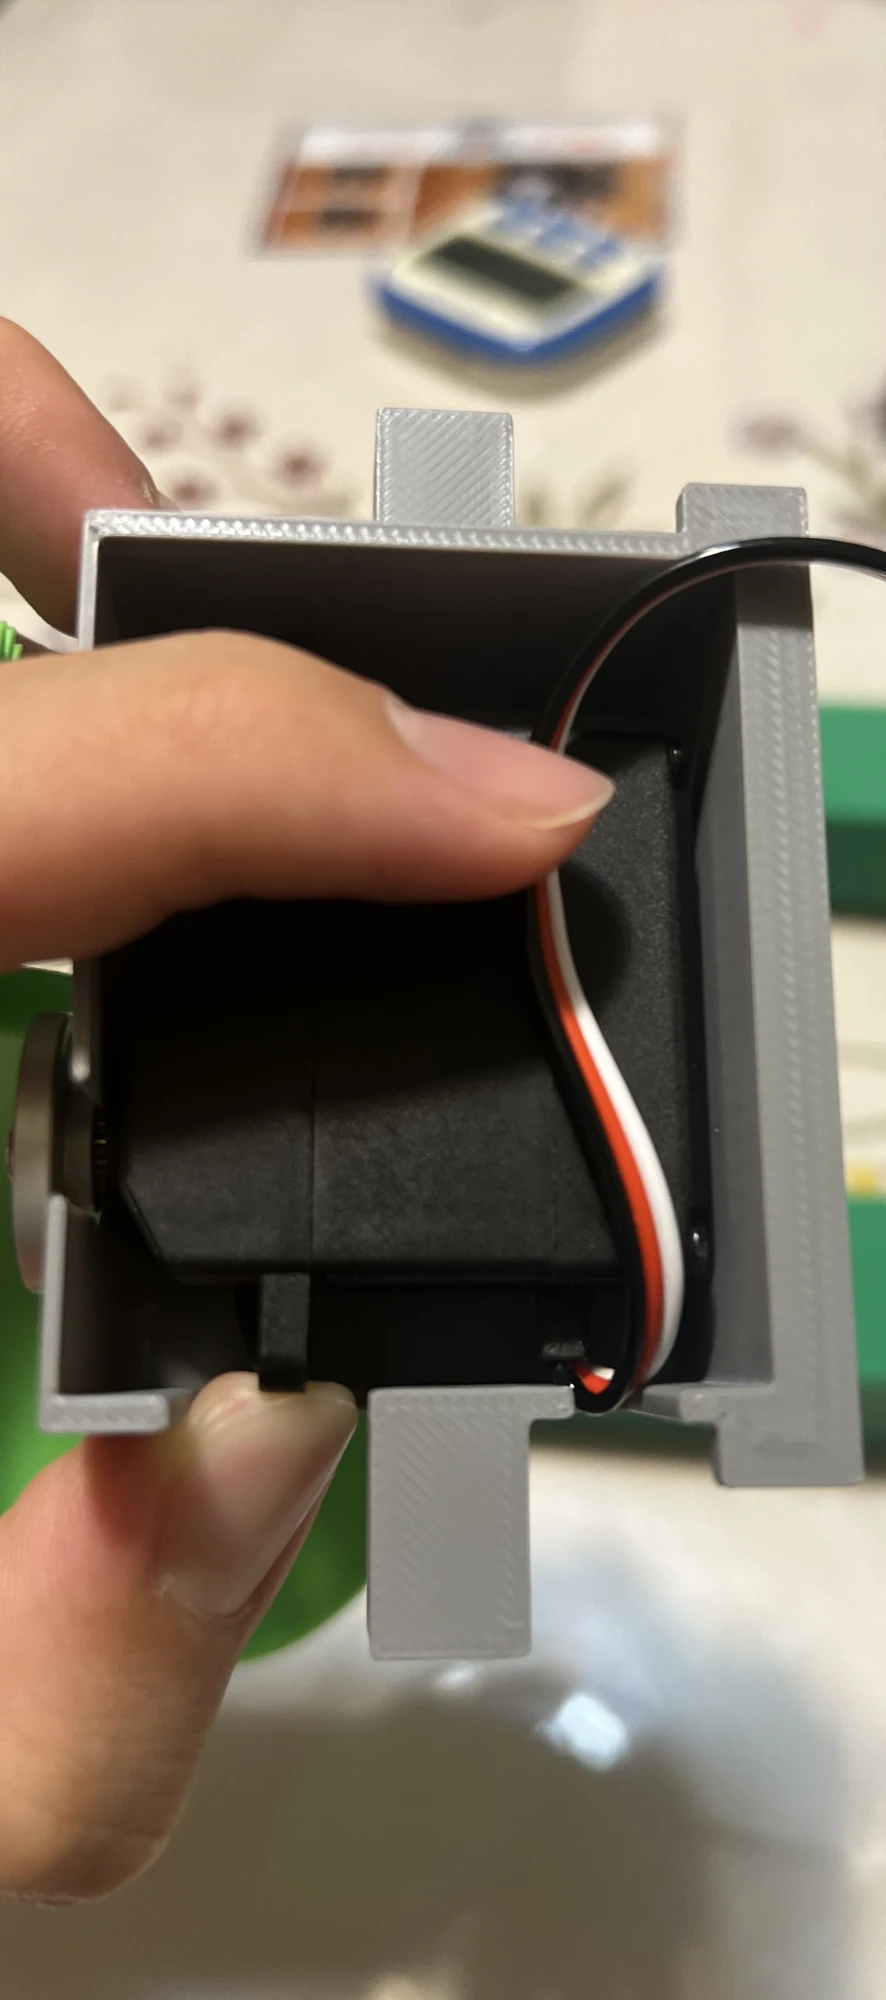
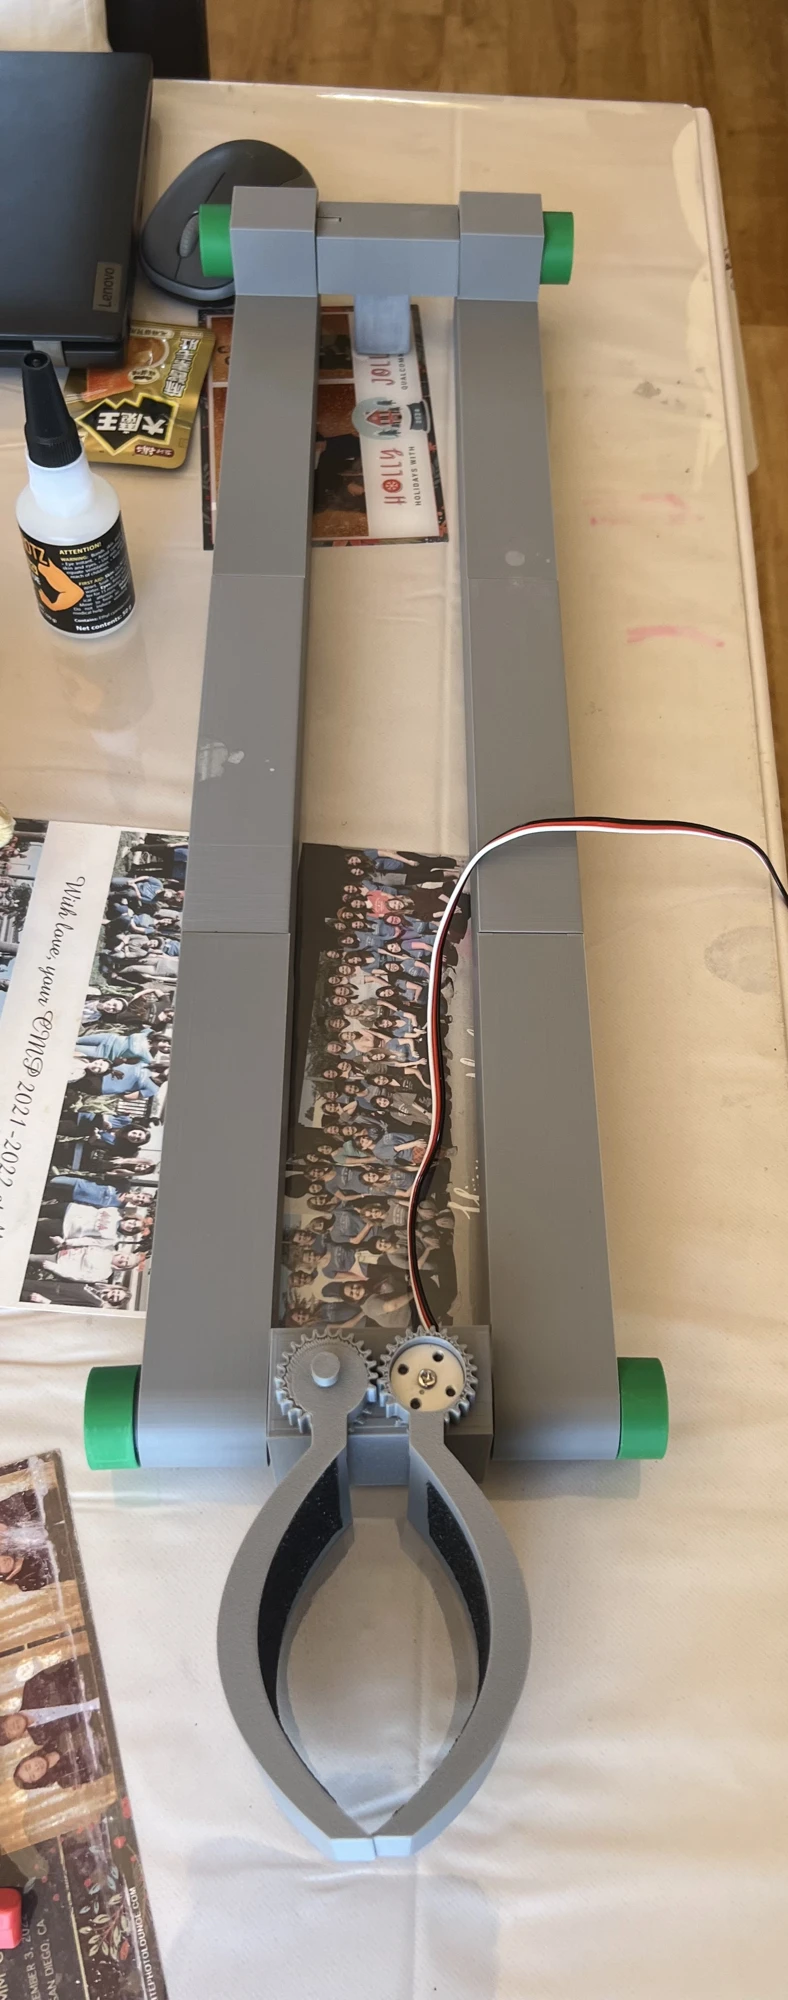
Our first printed prototype brought the CAD design to life. The mechanism worked, but its weight limited how long the drone could carry it, and the claw could not grip firmly enough to hold an object securely. These limitations prompted further adjustments.
- 04
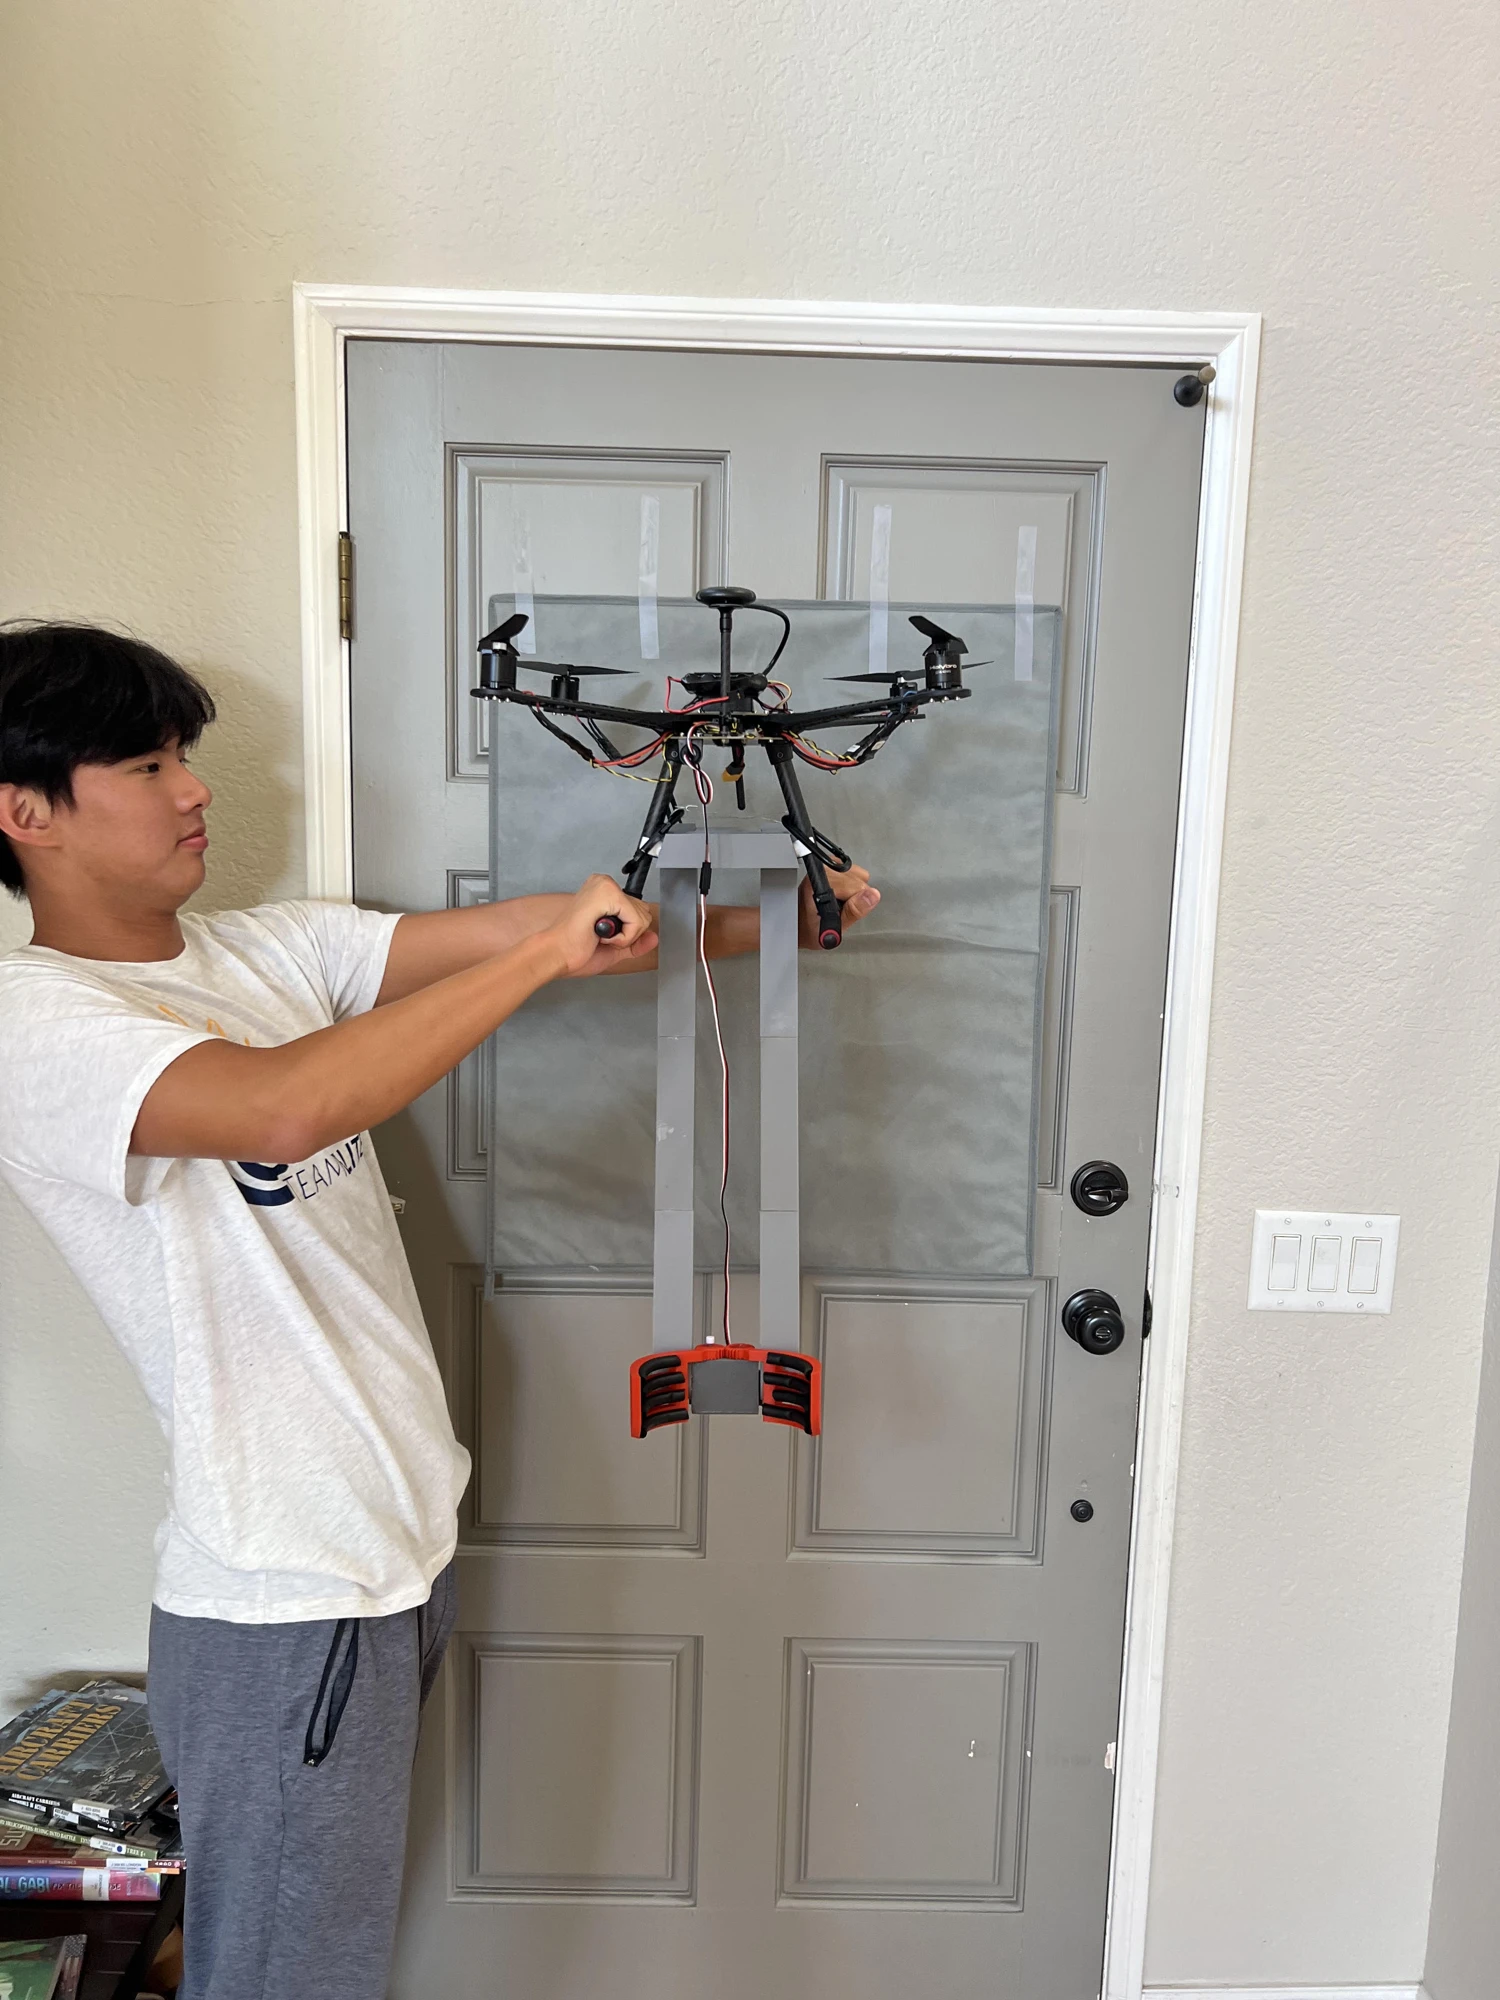
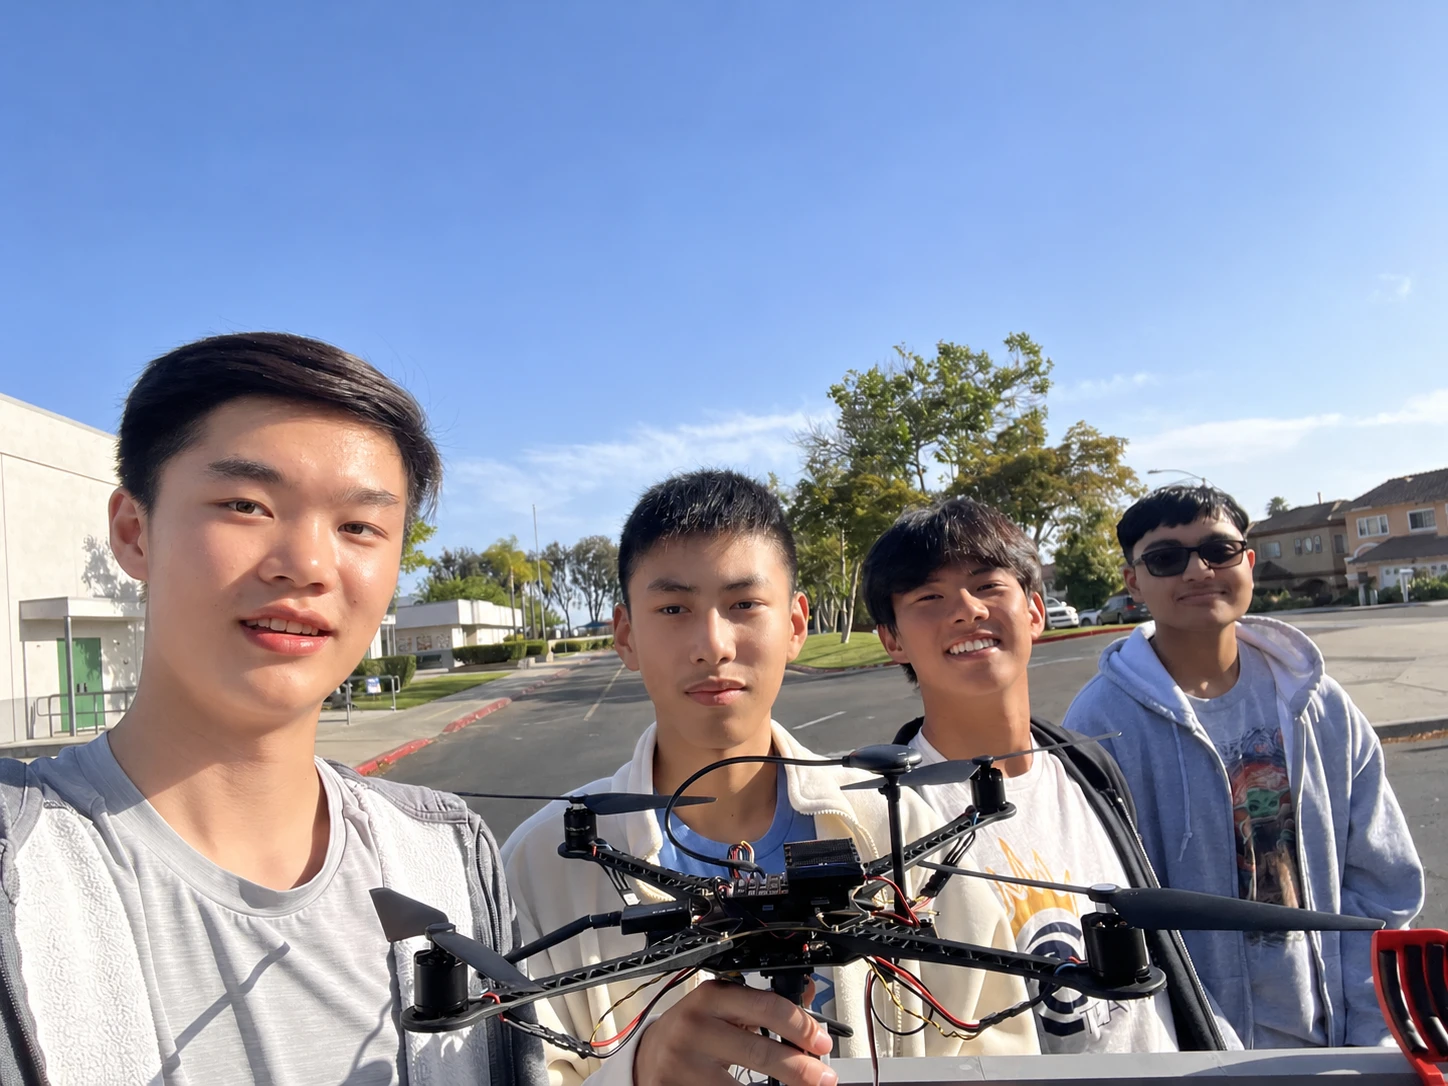
We hollowed the parallel supports to reduce weight while preserving their outer shape. Horizontal cutouts lightened the claw, while rubber grip strips along the inner jaws improved its hold on objects.
- 05
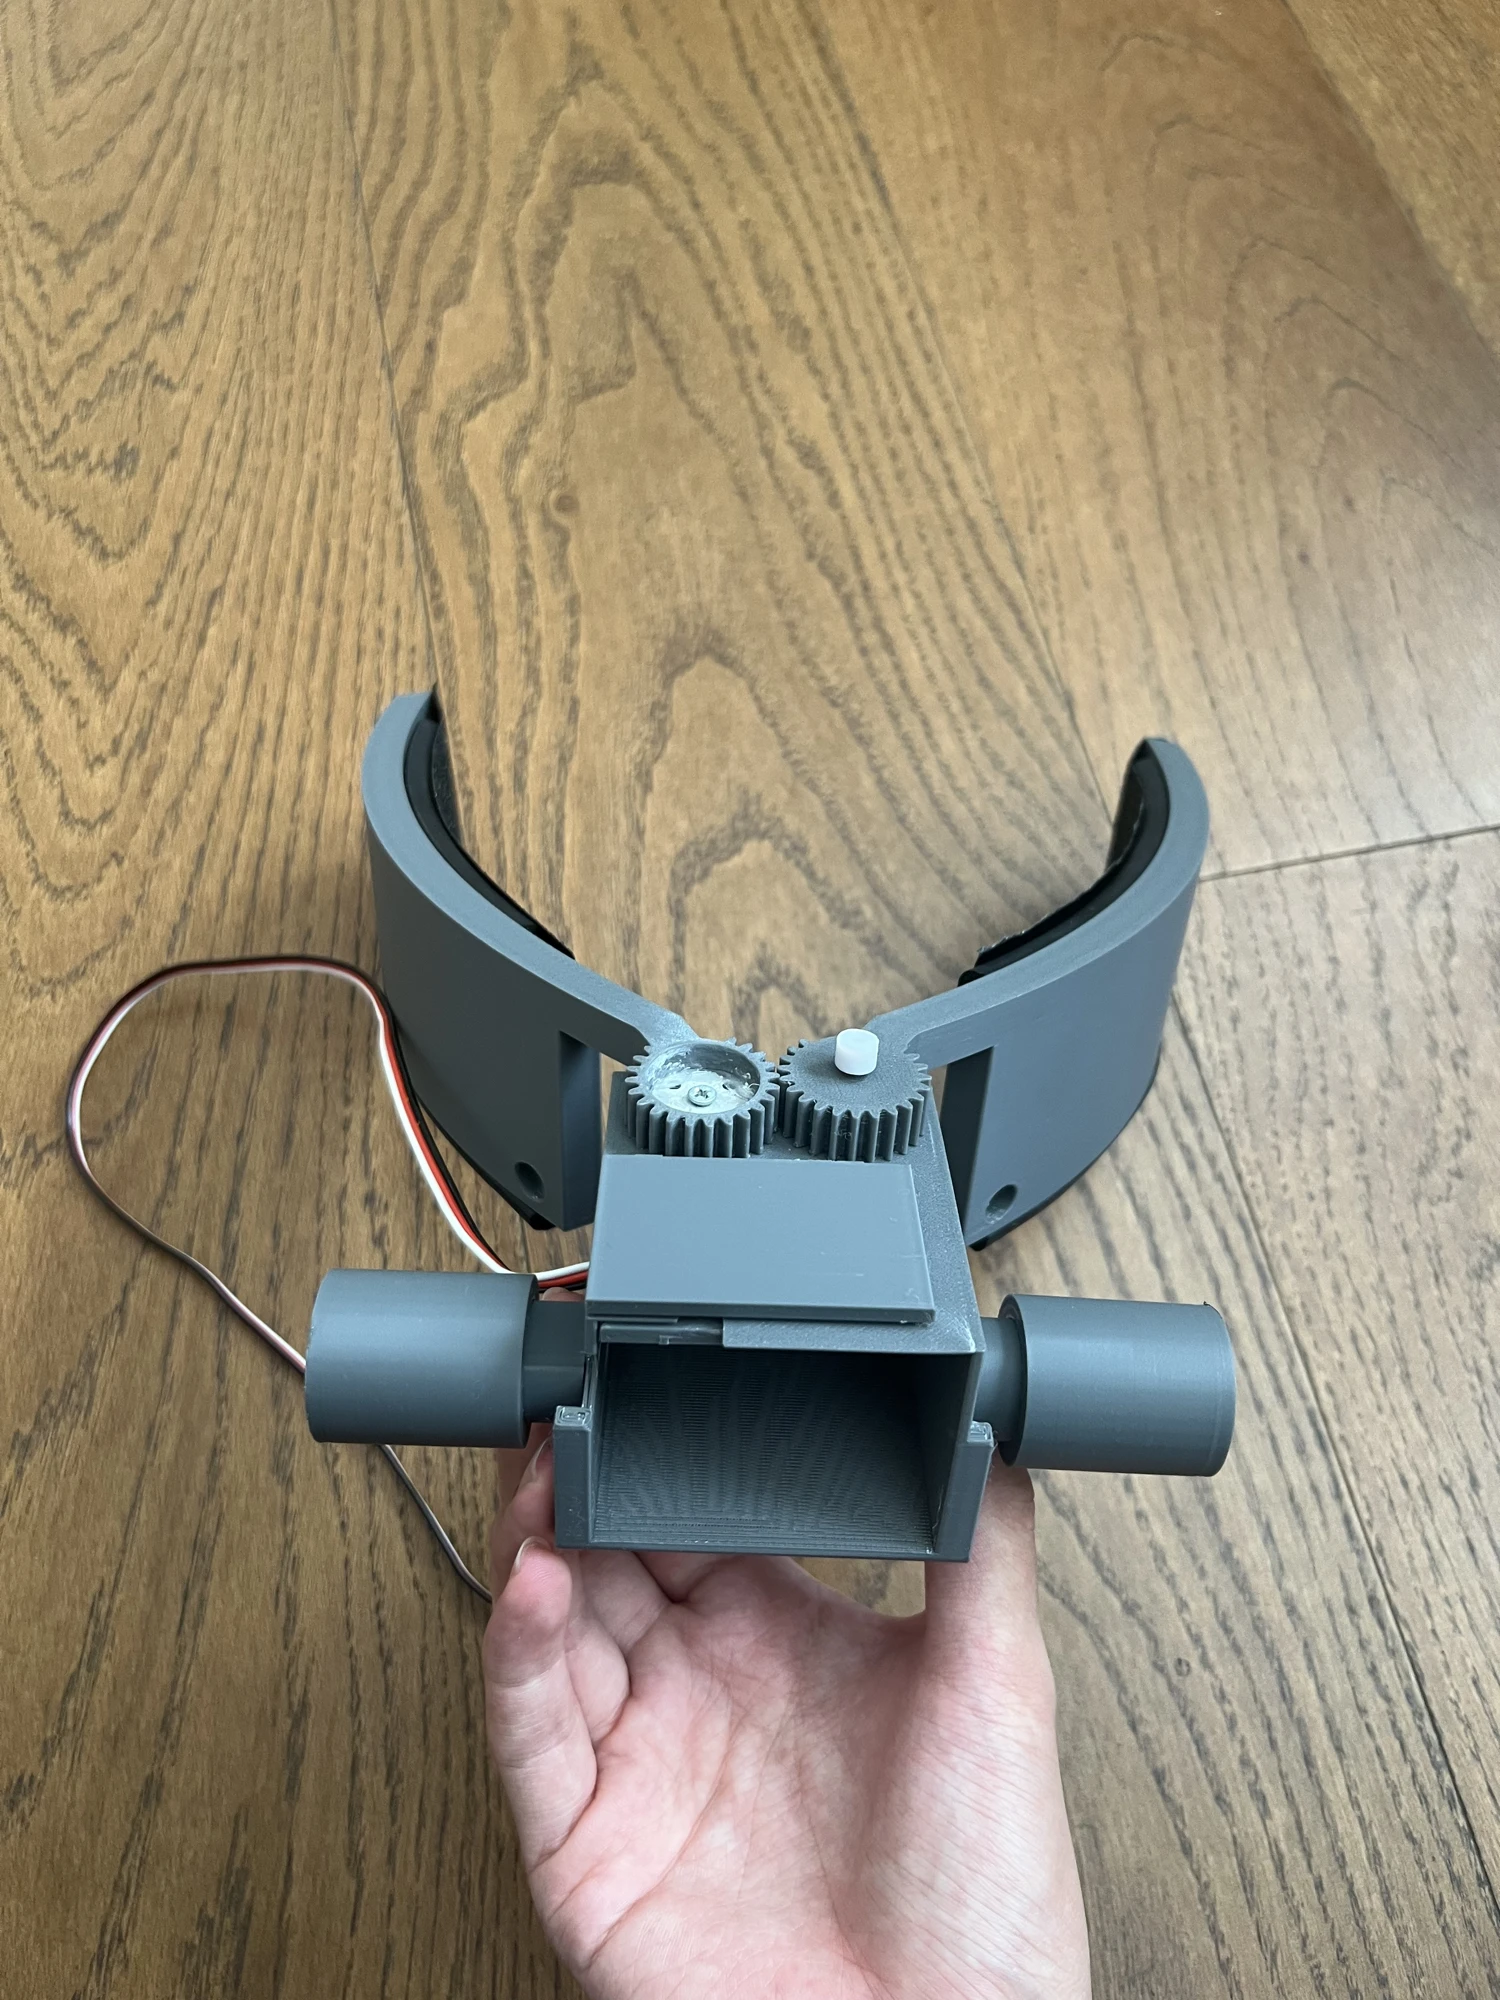
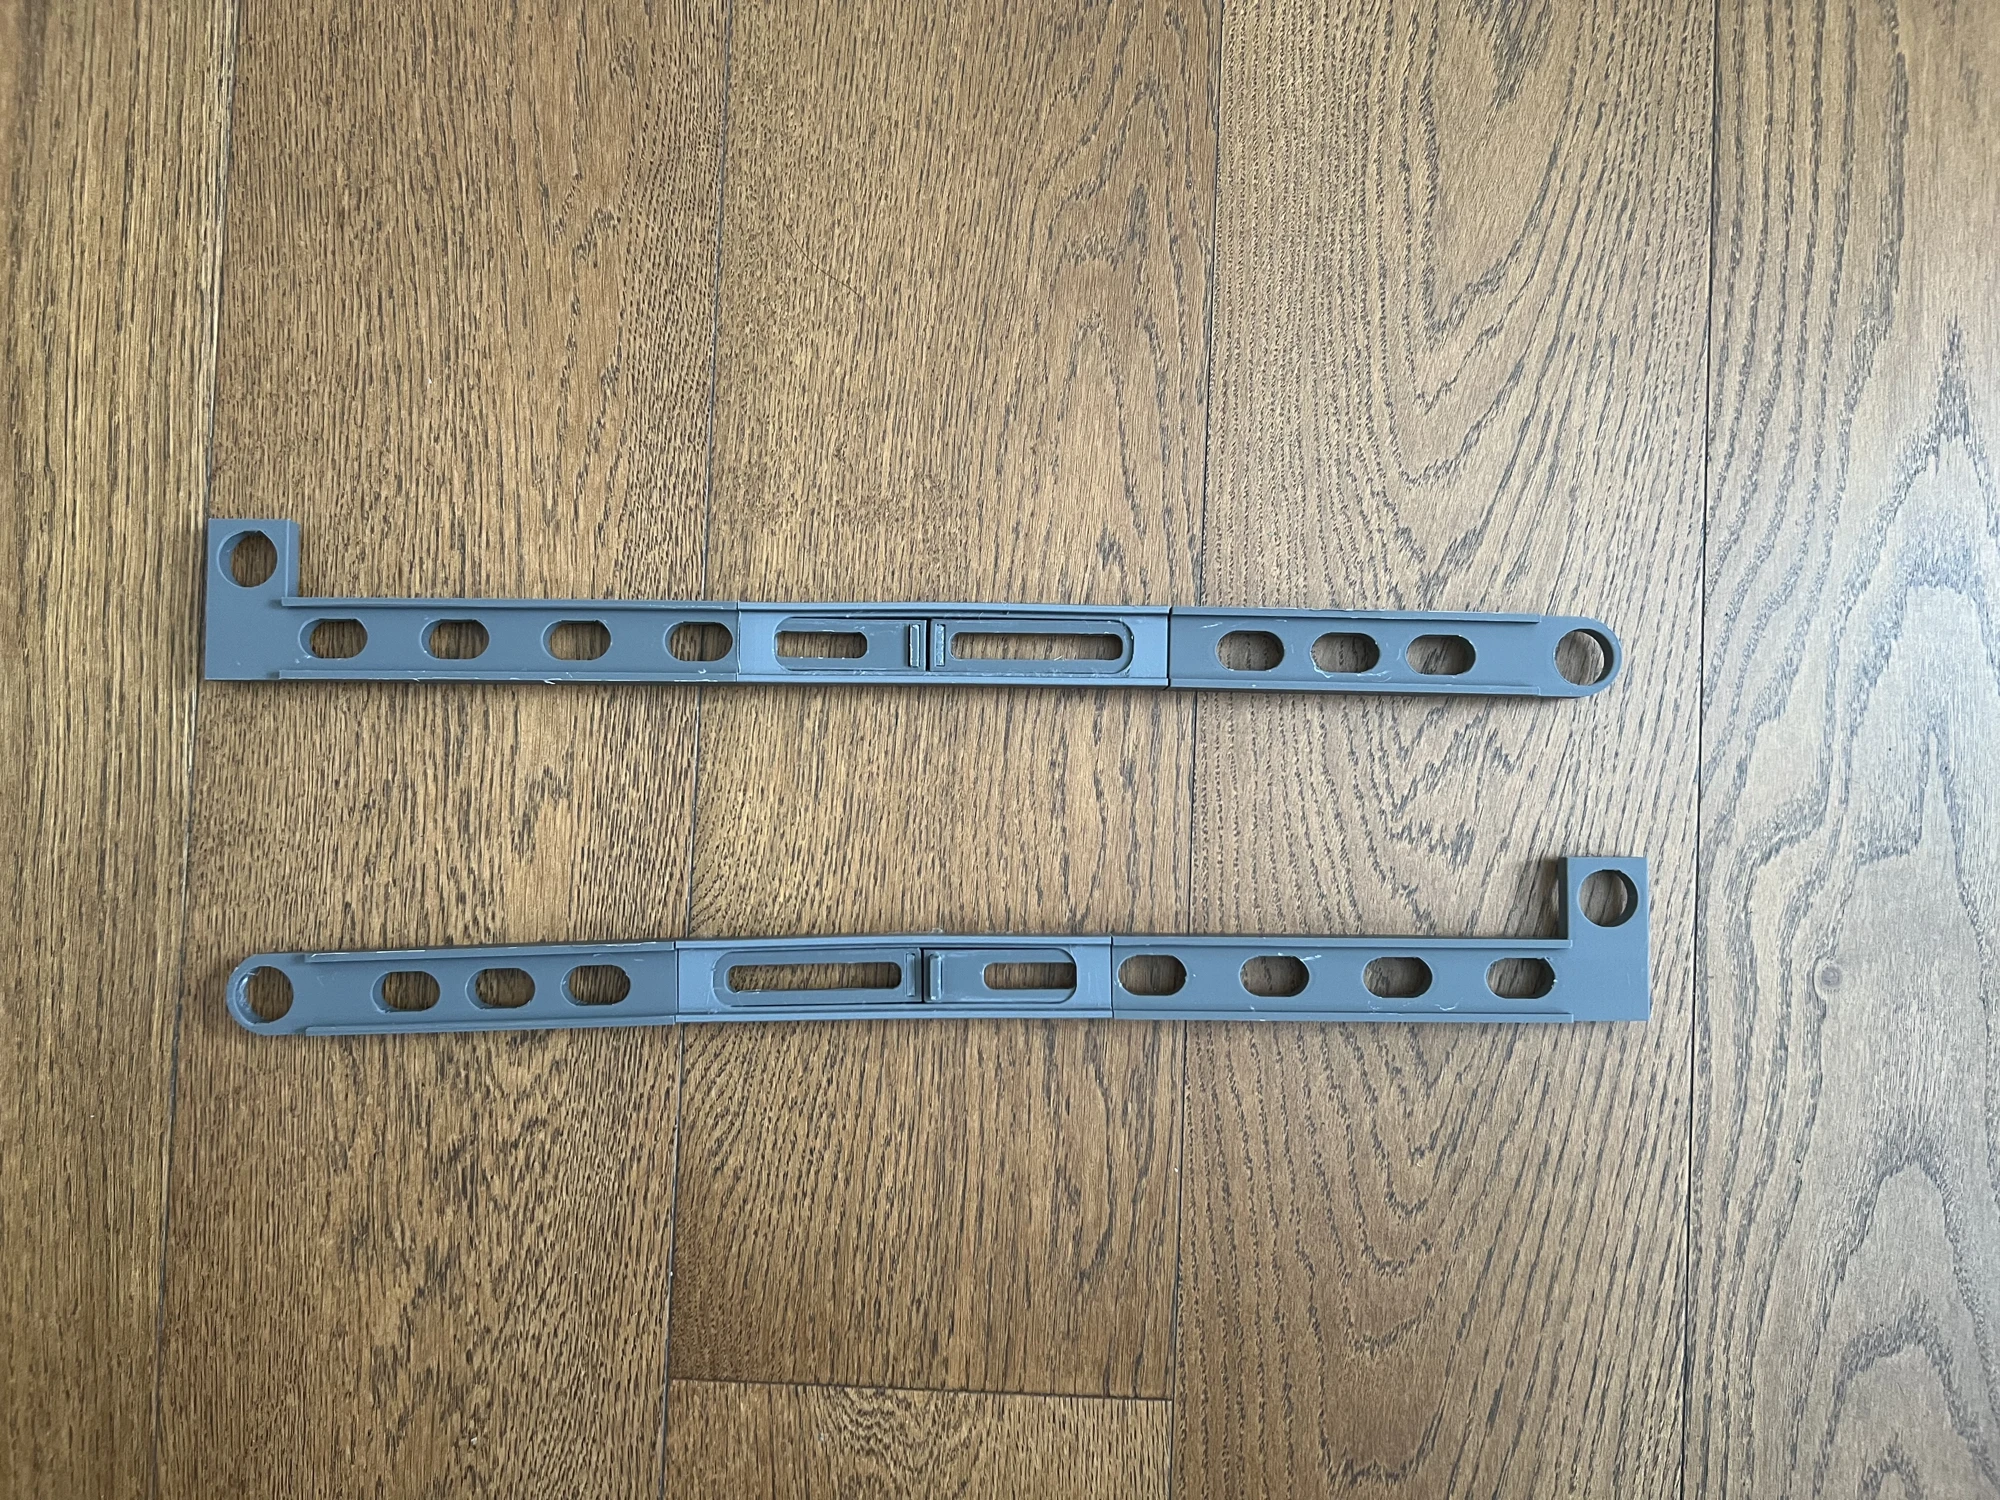
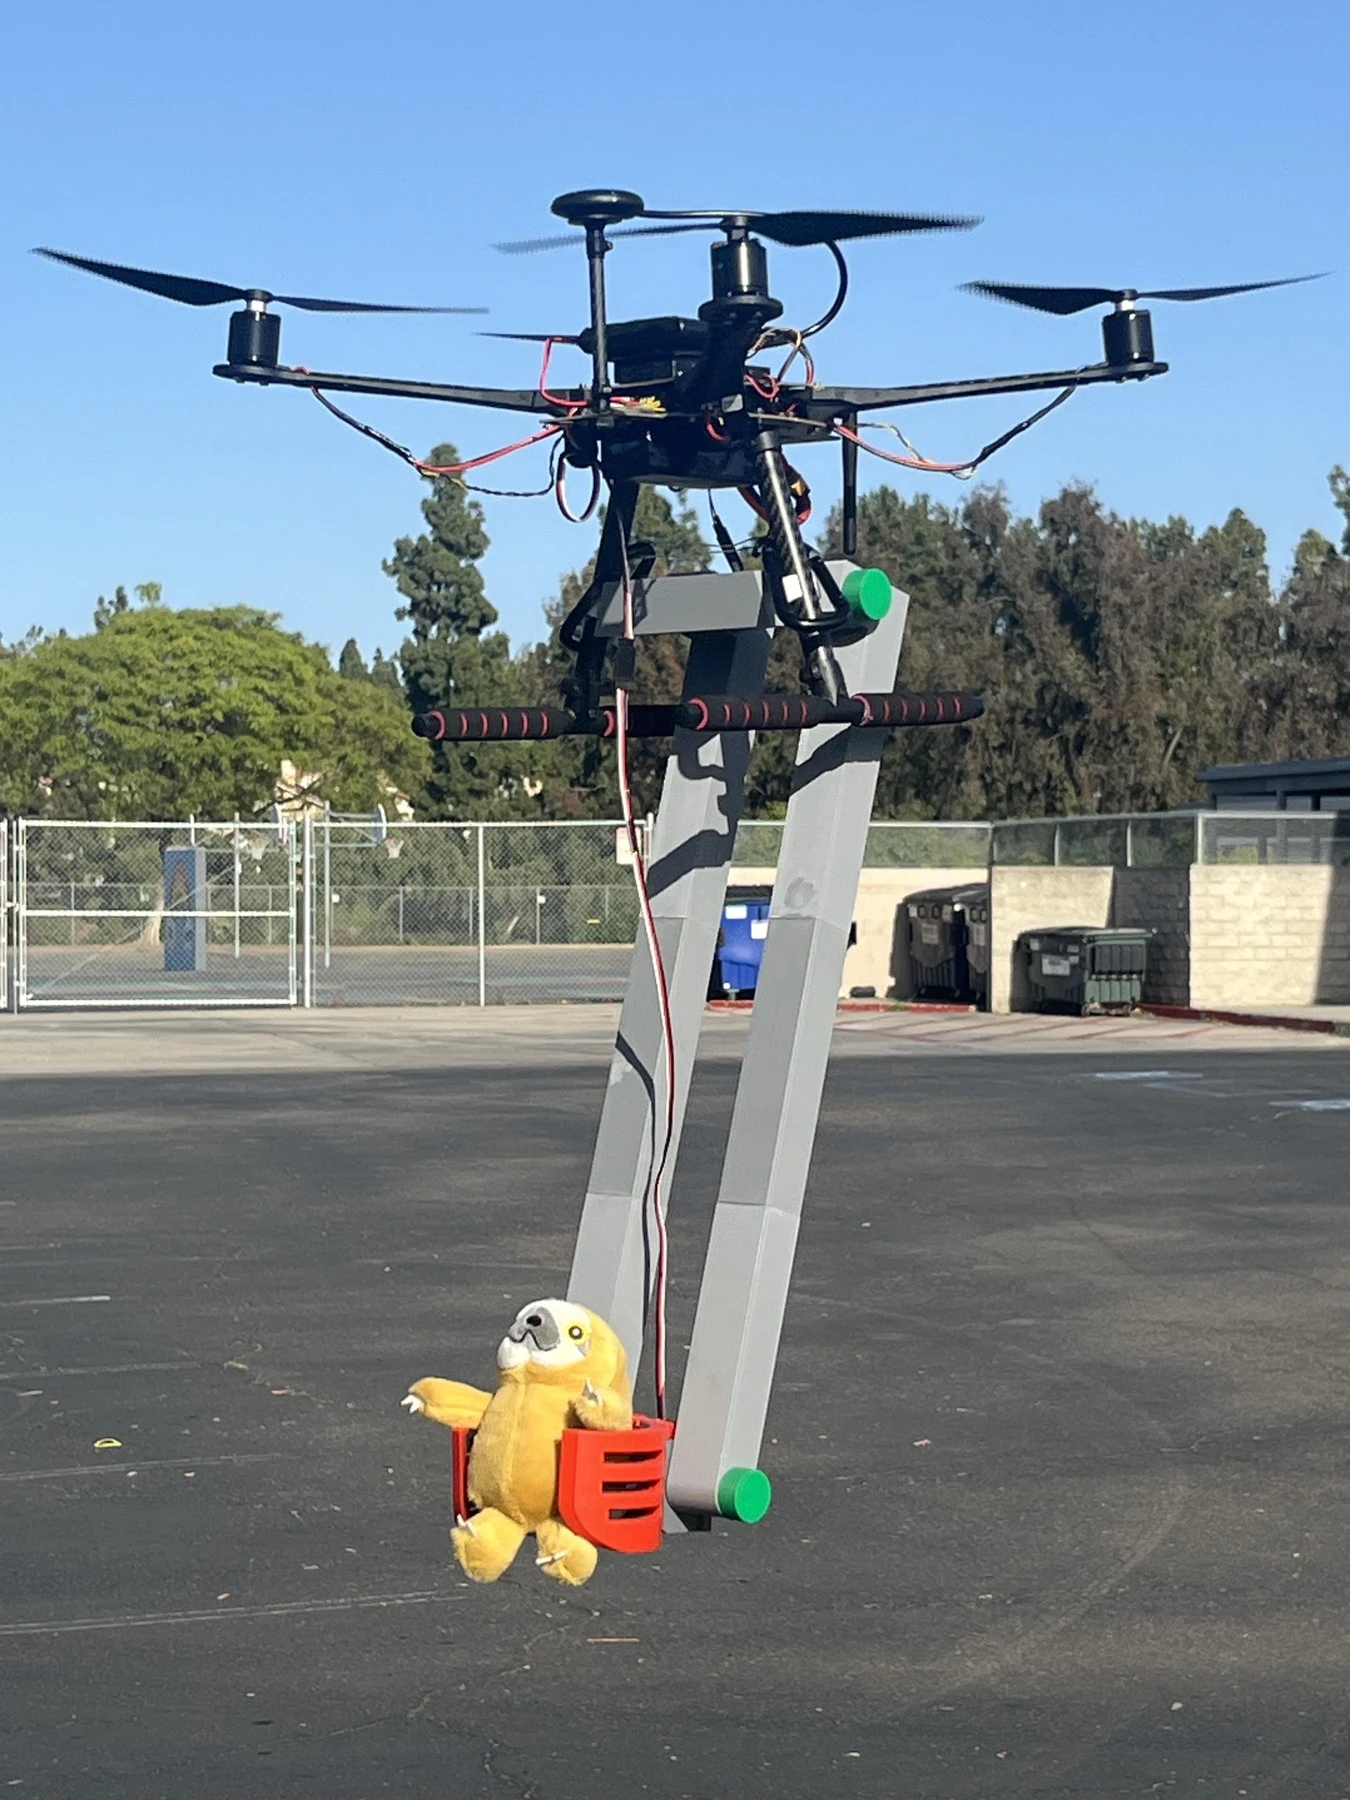
This was the final arm and claw design we used in competition. Sandpaper over the rubber grip strips increased friction for a more secure hold, while additional cutouts in the middle sections of the arms reduced weight further.
- 06
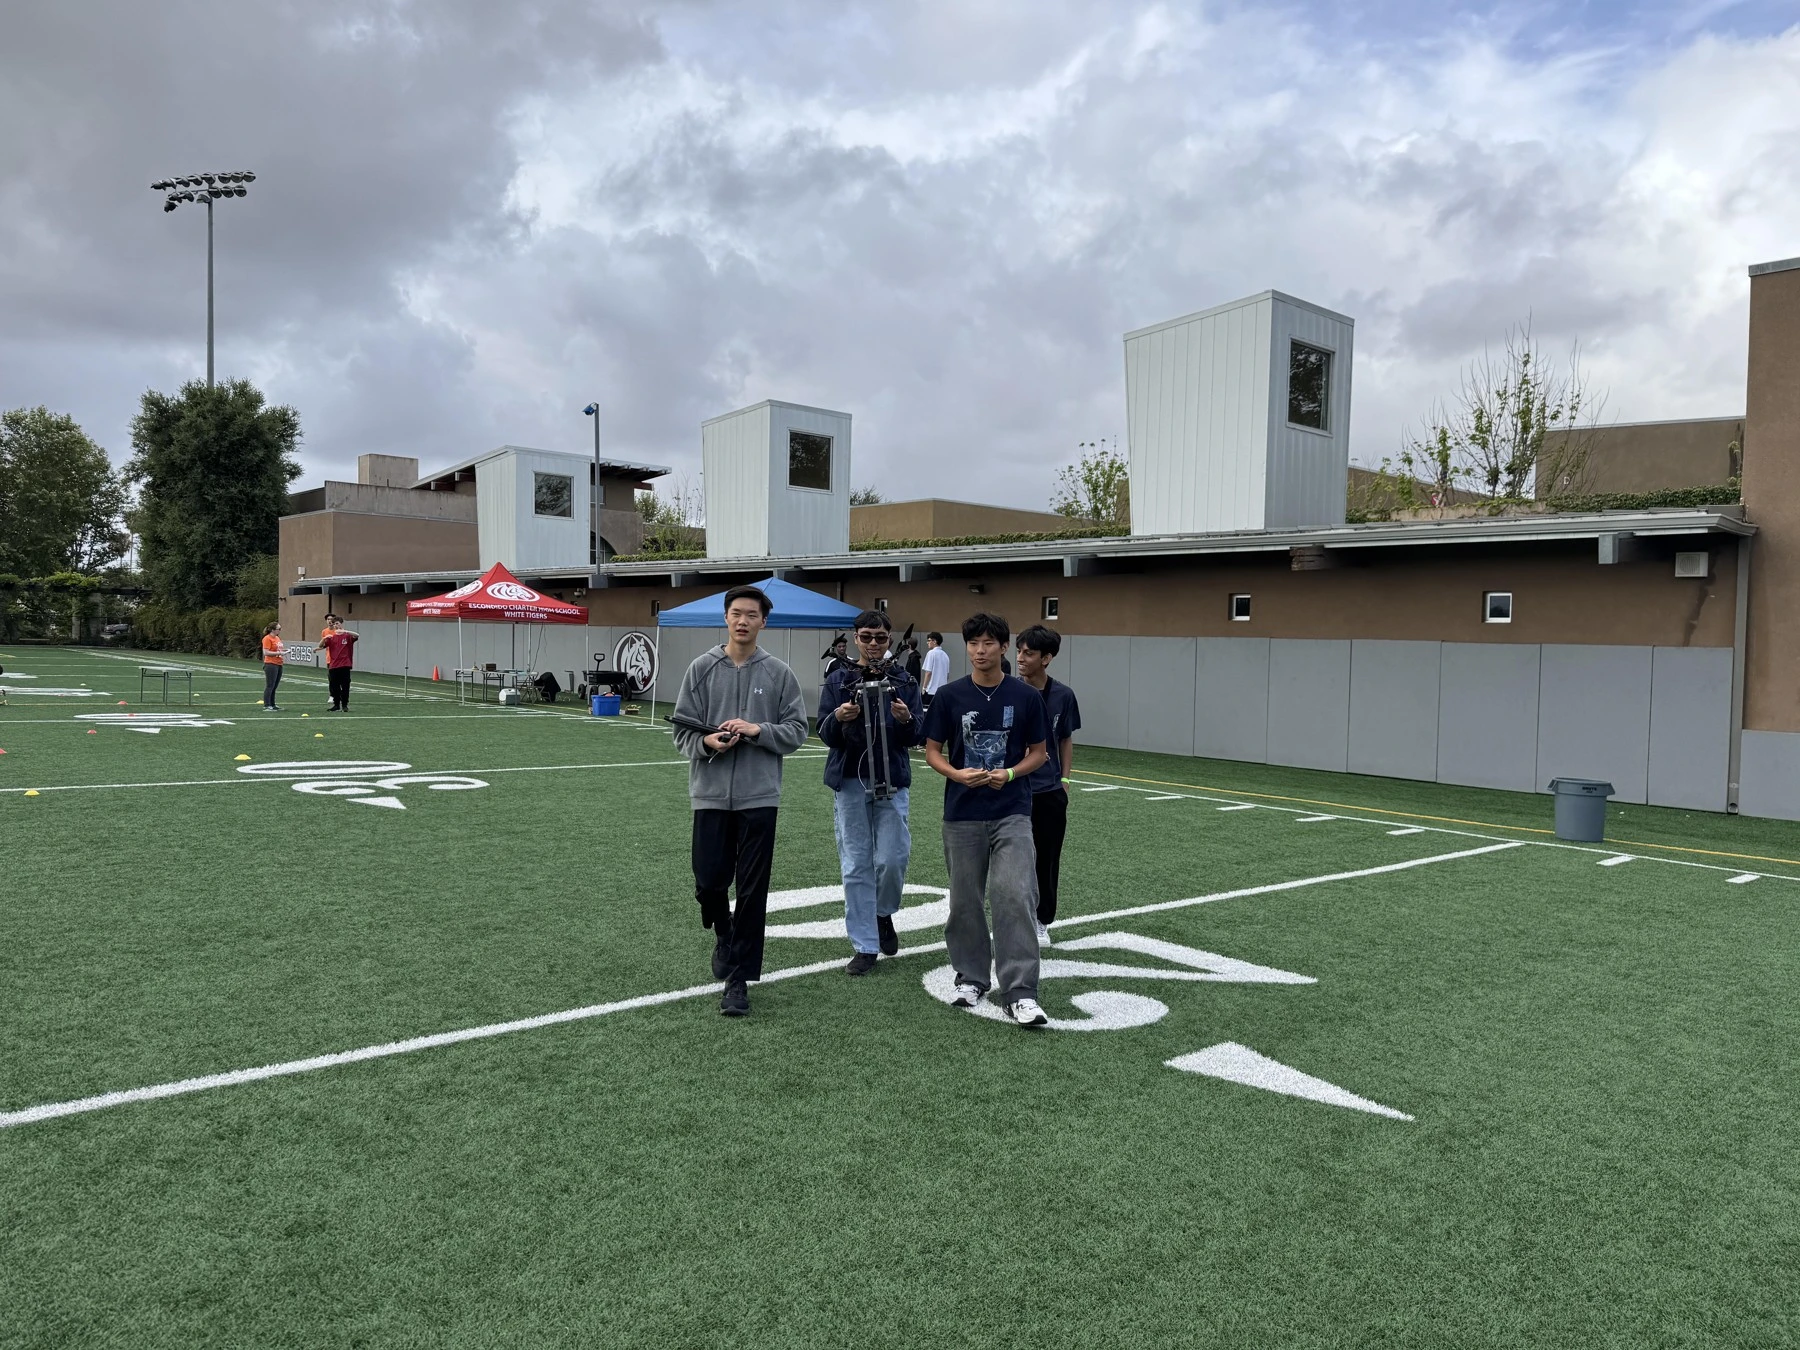
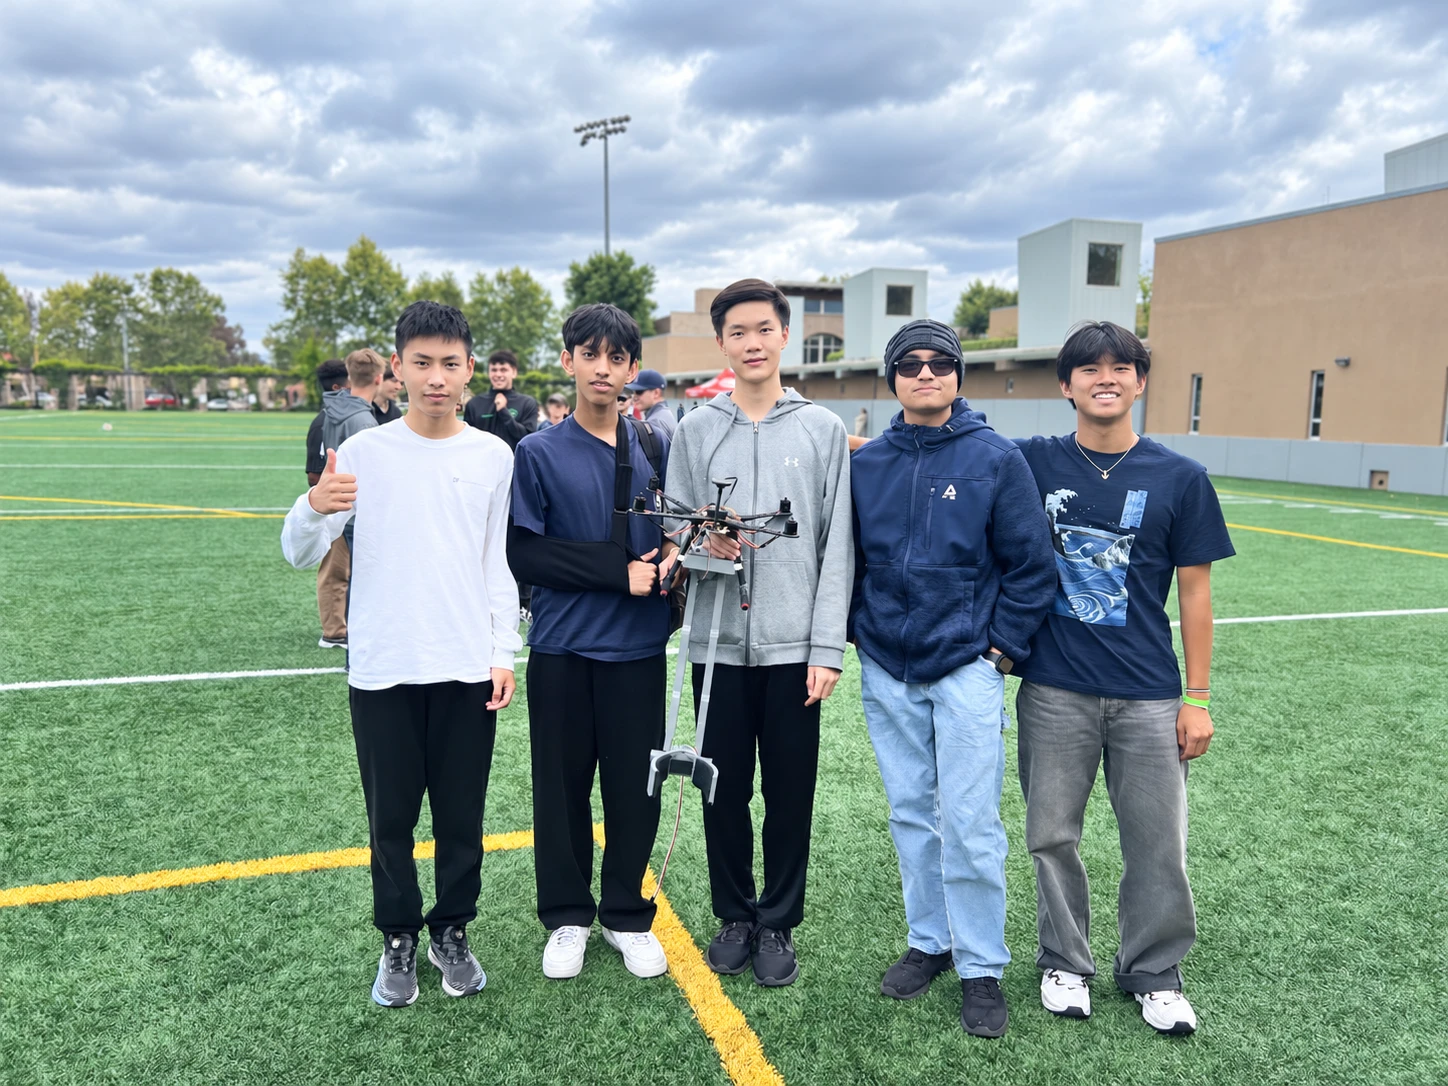
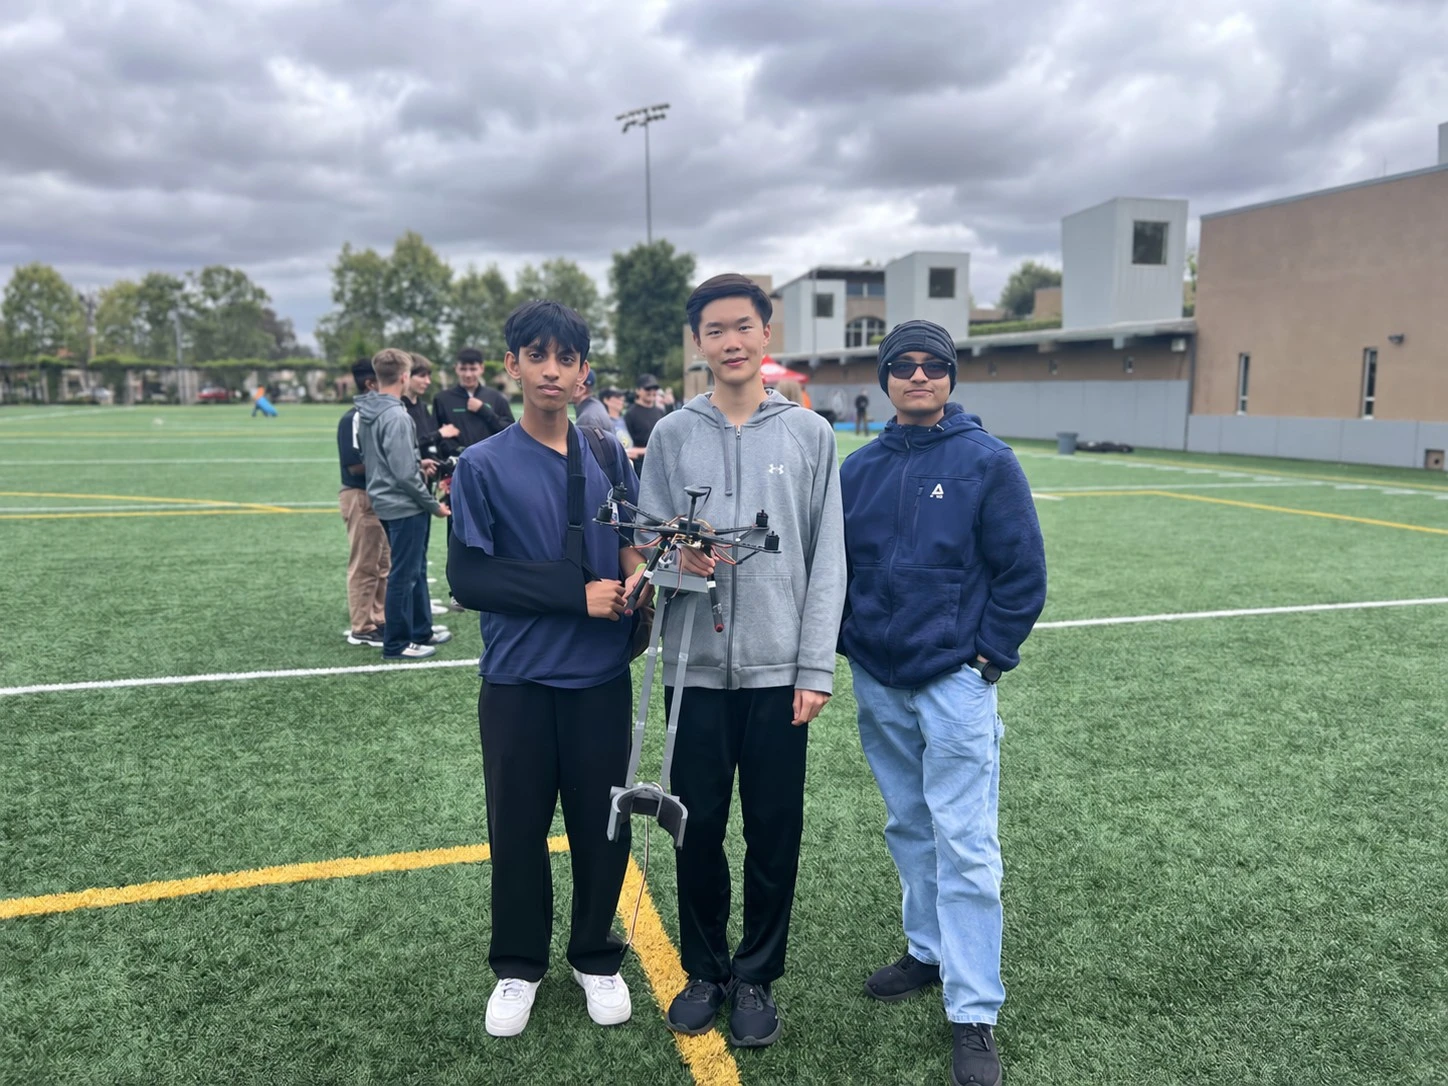
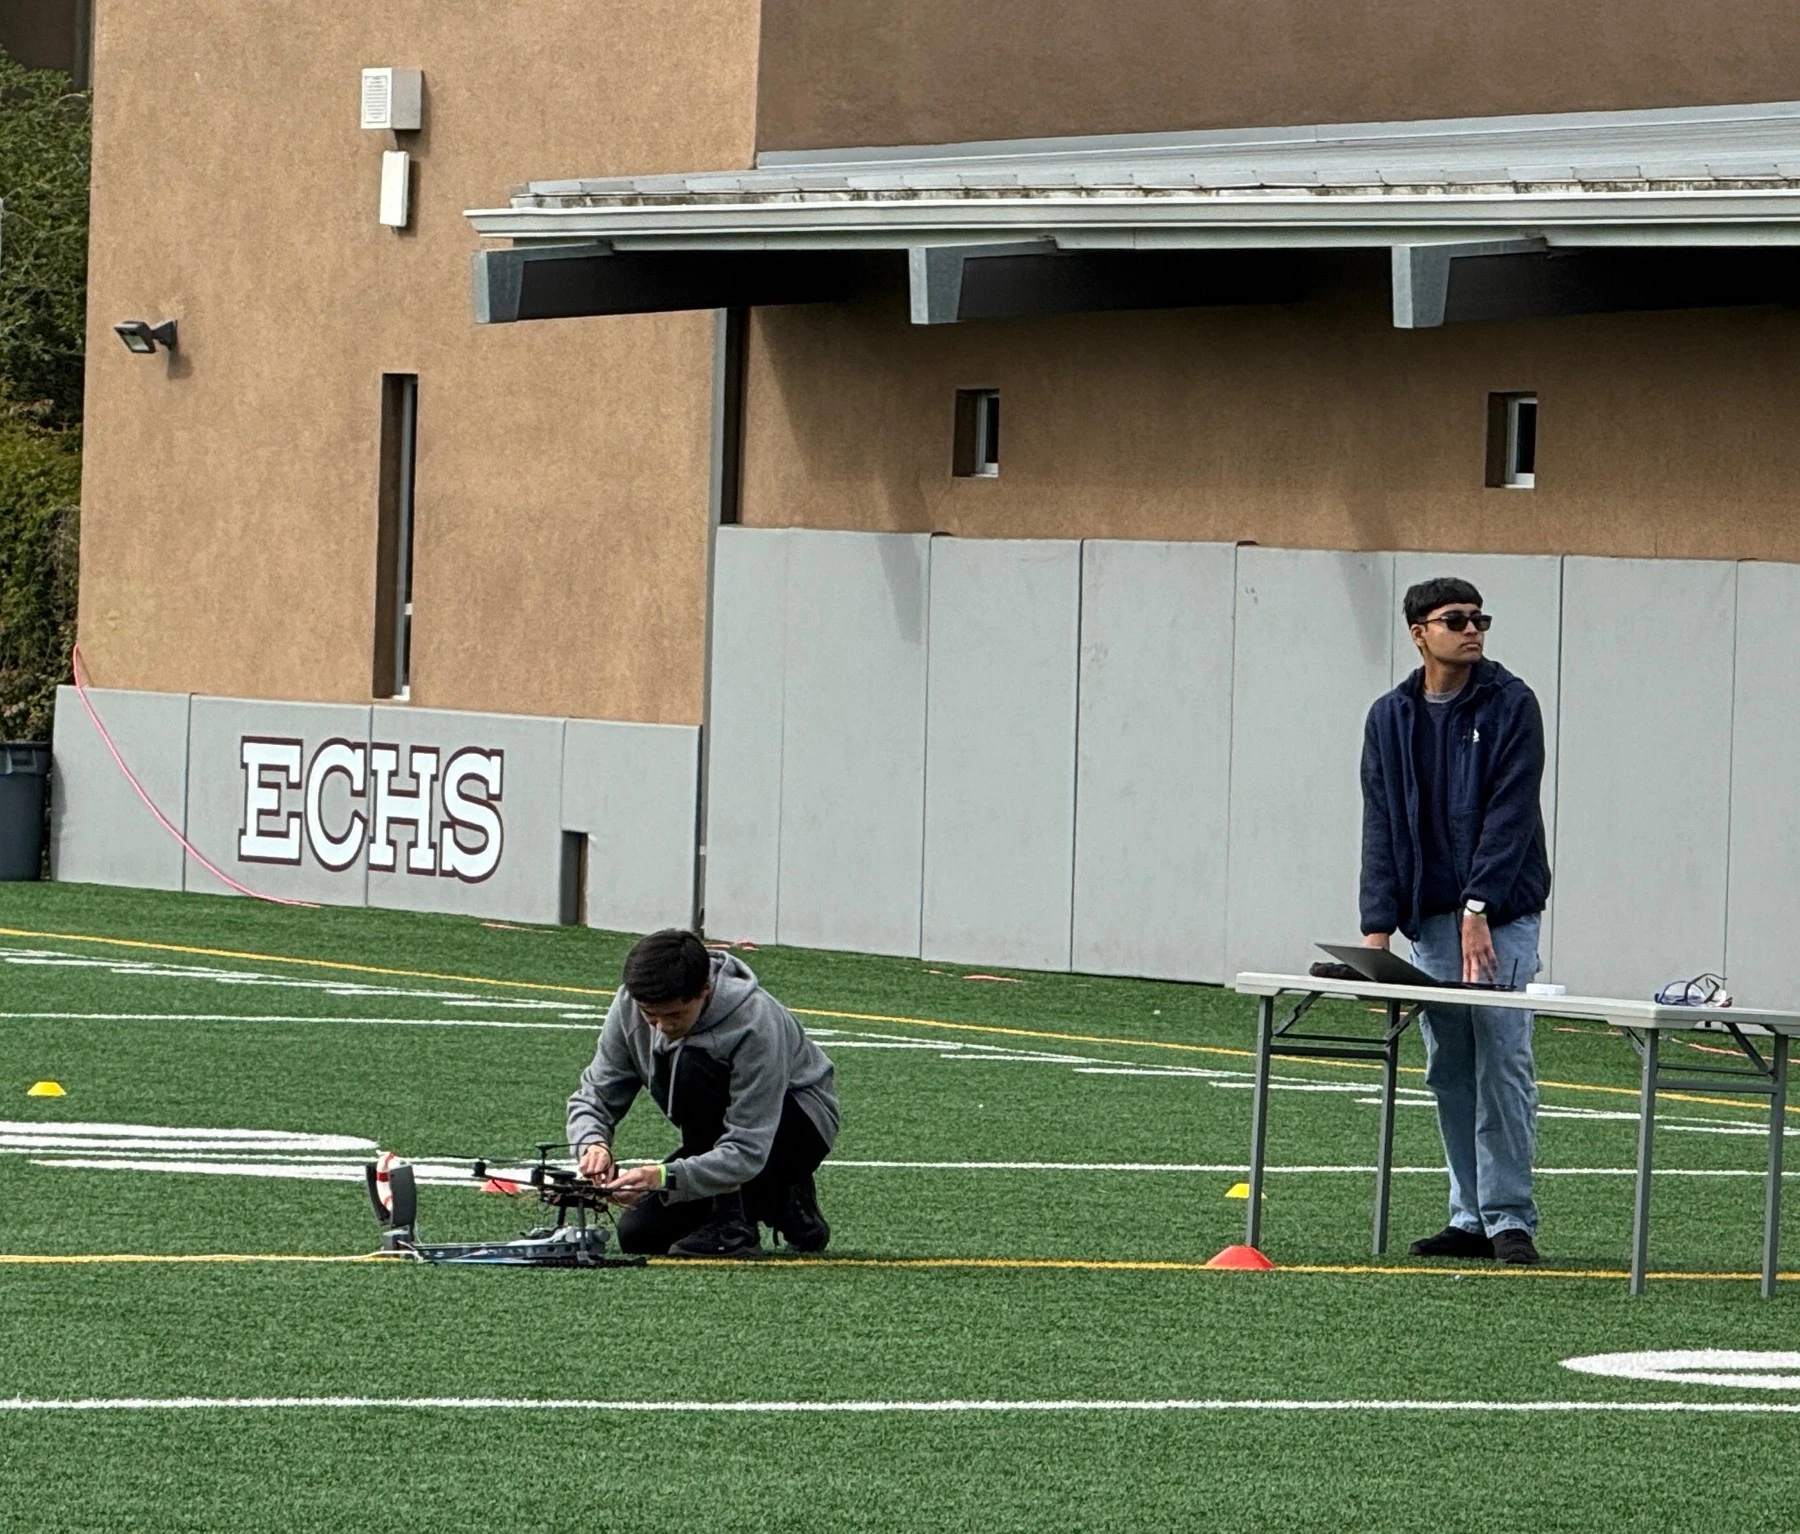
Competition Day!!!
Reflection
This project taught me to look beyond whether a mechanism moved and ask whether it worked as part of the whole drone. Our first printed prototype operated, but it was too heavy to carry for long and could not grip an object securely. Each revision made us confront something the CAD model alone could not settle. The hollowed arms, lighter jaws, rubber strips, and sandpaper were our responses to those problems.
The harder lesson for me was learning to give other people’s ideas a fair test. When new teammates first proposed a printed claw, I chose the familiar metal design before fairly exploring their idea. I had recruited a team, yet I was still making decisions as though the project belonged to me. Reopening that decision and developing their prototype together changed both our mechanism and my understanding of being captain.
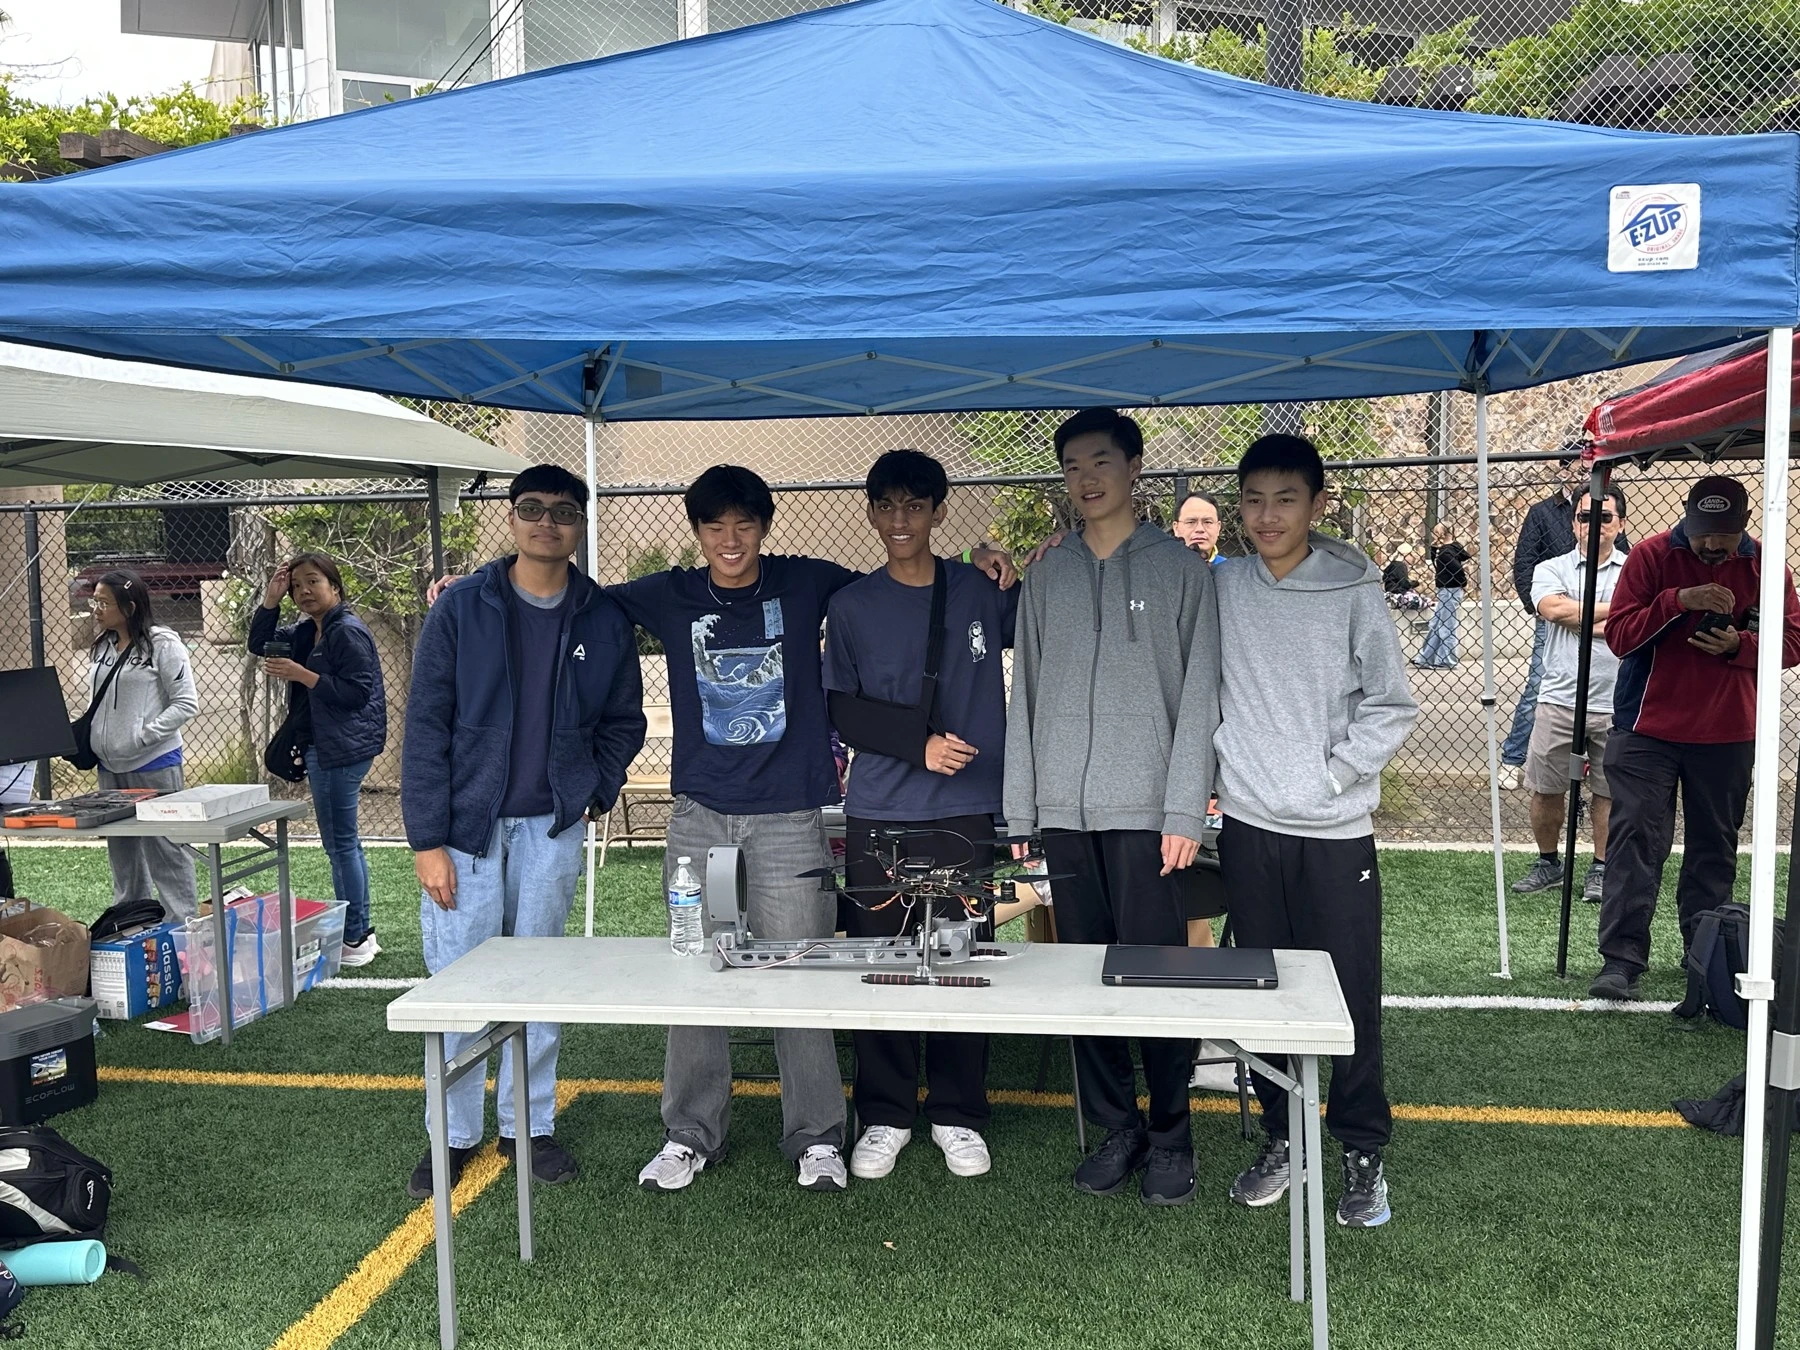
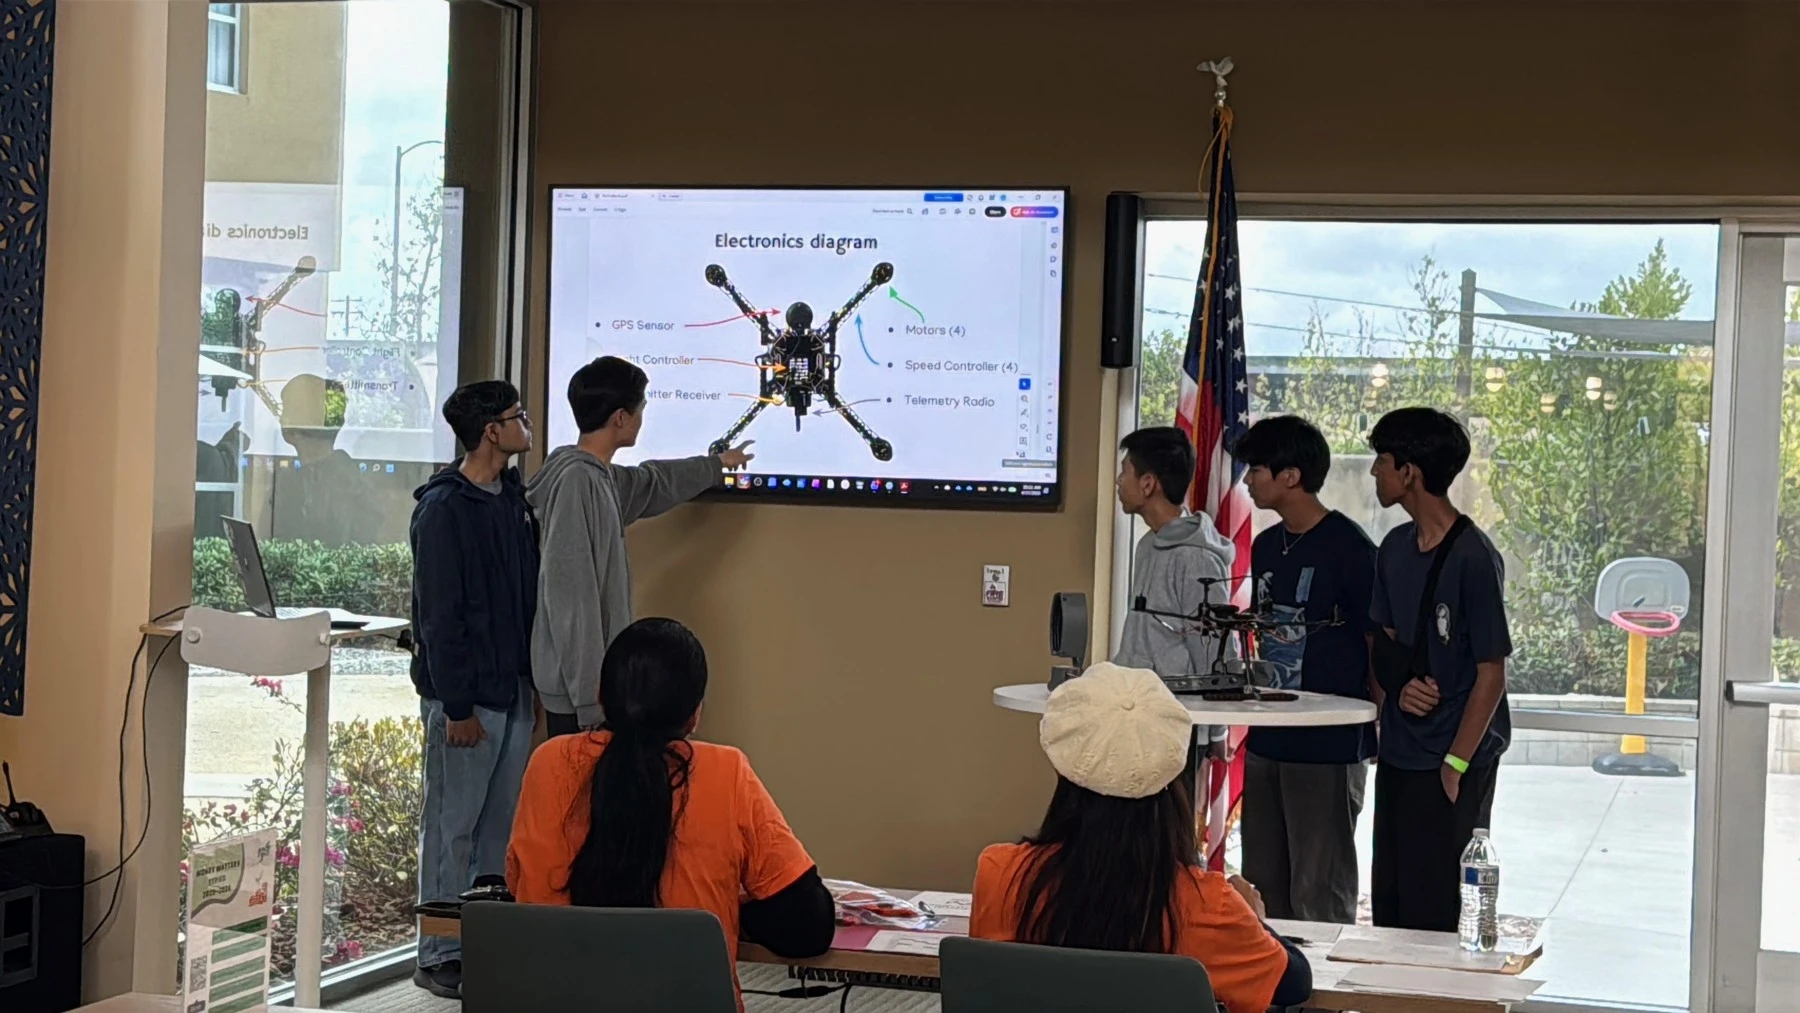
I think about that change when I look at these photos. Every version depended on contributions beyond my own, including the final fittings another teammate handled. I learned that listening meant leaving enough room for someone else to speak, even when everyone was looking to me for an answer. What I want to carry forward is that willingness to trust other people with something I care about.
It was my honor to captain the Do Do Birds for the past 3 years, and I give my best wishes for Adam and Benny to continue the legacy.